External Interface
Current Source 1 and 2
Two 12 V switched current sources, which can source a maximum of 200 mA each are supplied on pins 3 and 5. The 12 V supply is internally generated and is battery backed and so can still be used when running of solar or battery power. Current supplied by each of the switched current sources is measured to a resolution of 0.1 mA and so is able to be used to supply and measure the output of 4-20 mA and other current-output sensors. Internal resettable fuses protect the outputs against over-current events.
The switched current sources are expected to be used to power external sensors such as hall-effect sensors, 4-20 mA sensors and serial devices. It can be configured to turn on prior to measurement to allow sensors time to boot or for measurements to stabilise. After measurements are complete, the output can be switched off to preserve power; this is especially important when running off solar or batteries. The current sources can be used to power a sensor that is measured using one of the inputs, since the inputs are measured just before the current sources are turned off.
Note
When a current source is used to power a sensor that is read by an input, the intervals specified for the current source and input must be the same.
Many 4-20 mA sensors are powered by the current flowing through the loop to which they are connected and are called loop powered devices. Loop powered sensors can be connected using switched source 1 as the current source (pin 3) and GND (pin 2 or 4) or alternatively using switched source 2 as the current source (pin 5 as shown below) and GND.
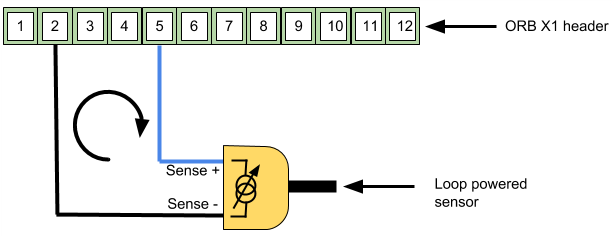
Connecting a single loop powered device
Some sensors and systems that use current as an output require an external power supply. In an implementation where system power is available, the sensor can be connected as shown below.
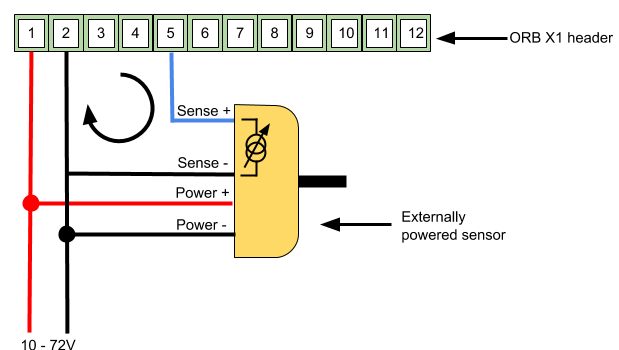
Connection of a single externally powered 4-20 mA device
In solar or battery operated systems where permanent power is not available, externally powered current-output sensors can utilise the ORB switched power source as shown below. Switched source 1 and 2 should be configured to switch on for the minimum amount of time before a measurement is made in order to minimise power consumption.
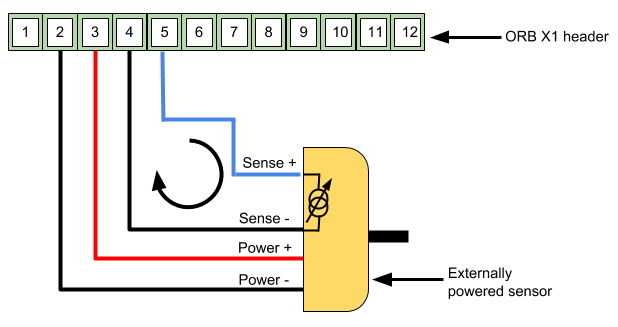
Connection of a single externally powered 4-20 mA device using switched power
Two loop powered 4-20 mA sensors can be connected to the ORB by utilising both of the switched current sources.
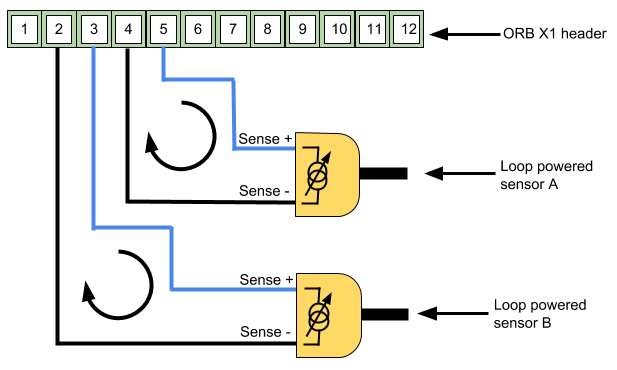
Connection of two loop powered 4-20 mA devices
Both inputs will report the voltage that is connected to them and so can be used as general purpose analog or digital inputs.
Note
When a voltage is connected to the current source pins, current may flow backwards into the ORB and the resulting current measurement may be negative.
Warning
Connecting a power source greater than 12 V to pins 3 or 5 may result in permanent damage to the functions of those pins or to the ORB.
Specification
Parameter |
Specification |
|---|---|
Maximum source current |
100 mA per pin |
Maximum measurable current |
40 mA |
Current measurement accuracy |
+-0.1mA |
Current measurement precision |
20uA (11 bits over 40 mA) |
Maximum voltage on pins |
12 V |
Voltage measurement accuracy |
+-300mV |
Settings
Measurements can be scheduled as a multiple of the base-interval. At the Interval, the current sources will turn on and a measurement will be made. The fastest possible measurement rate is achieved by setting the interval to 1 in which case measurements will occur on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the measurement-interval.
If a connected device needs some time to stabilise before measurements can be taken, the current sources can be set to turn on a short time before a measurement is to be made using the Start Time option. Keep the Start Time value to a minimum to reduce overall power consumption when running on batteries or solar.
Note
If more than one external device is being powered by the switched power, please ensure that the stabilisation time is set to the maximum for all devices powered.
If the current sources are being used to power an external sensor device that needs to be constantly powered, the Always On option can be used to prevent the current source from being turned off.
The ORB measures current, in mA, sourced by the two outputs. If however the attached sensor is calibrated in a unit other than mA, then that calibration can be applied to the measurement. If for instance, a 4-20 mA level sensor is attached to output 1 and 4 mA represents 0 m of water and 20 mA represents 100 m of water, then the calibration values are set as follows:
current1.calibration.low_x = 4 |
4 mA is the low value at which the sensor is specified |
current1.calibration.low_y = 0 |
0 m is the value represented by 4 mA |
current1.calibration.high_x = 20 |
20 mA is the high value at which the sensor is specified |
current1.calibration.high_y = 100 |
100 m is the value represented by 20 mA |
current1.calibration.unit = m |
m is the unit as measured by the sensor |
The mA values measured by the ORB will be converted into the user specified units before being transmitted or being compared with the warning and alarm values. If the user wants to leave the units in mA, then use the defaults as specified in the table below.
The input measurement range and accuracy can be optimised specifically for 4-20 mA devices. Select the optimise option to optimise accuracy for 4-20 mA sensors.
An alert can be set on the current measurement. Each time a measurement is completed, it is compared with the low and high thresholds. If either is crossed, an event of the chosen alert type is raised and a message is transmitted immediately, then at the exception interval while the event lasts. Hysteresis, set in the measurement’s units, prevents repeated alerts in the presence of electrical noise. See Warnings and Alarms.
A full list of current source settings is given in the table at the end of this chapter.
Serial interface
The serial port can be used to capture data that is sent from an external system or to interface to a MODBUS sensor.
The ORB-C1 contains two terminals marked A / TX and B / RX on the interface header. The pins have functions that depend on the chosen interface as shown in the table below. When RS485 mode is chosen, an optional 120Ω termination resistor can be selected.
Interface type |
B / RX function |
A / TX function |
|---|---|---|
RS232 |
Receive (Rx) |
Transmit (Tx) |
RS485 |
RS485-B |
RS485-A |
Note
RS485-B is sometimes referred to as D+ or TX+/RX+ and RS485-A as D- or TX-/RX-.
The serial interface supports both RS232 and RS485 operation.
The interface incorporates protection features to improve robustness and reliability in industrial environment with the RS485 receiver offering full failsafe operation for floating, shorted, or terminated inputs.
Specification
Parameter |
Specification |
|---|---|
RS232 transmitter output low voltage (typical) |
-5.5V |
RS232 transmitter output high voltage (typical) |
+5.9 V |
RS232 input threshold voltage |
+1.5 V |
RS485 differential output voltage (minimum with load resistance 120Ω) |
+2 V |
RS485 differential input threshold (typical) |
+/-200mV |
Maximum nodes in RS485 mode |
256 |
RS485 termination resistor |
120Ω |
ESD protection |
+/-26kV |
Settings
Measurements can be scheduled as a multiple of the base-interval. The fastest possible measurement rate is achieved by setting the Interval to 1 in which case measurements will occur on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the Interval.
In serial capture mode the measurement interval can be used to reduce the number of readings being provided by a connected sensor or system that may be permanently powered. If for instance, a connected system is sending a message every second but it is only required to be read and transmitted every minute, the measurement interval can be set to 1 minute in which case the device will wake on the minute interval, receive a message and return to sleep thereby missing the other 59 messages sent by the attached system. Since serial packets cannot be interrogated by the ORB-C1 without a customised script, it makes sense to set the measurement interval to the same as the transmit interval in most cases.
The serial port on the ORB-C1 can be configured as an RS232 or RS485 hardware interface using the Type option.
An optional 120Ω RS485 termination resistor can be selected by turning on Termination Resistor. The purpose of the termination resistor is to match the impedance of a transmission line to the hardware impedance of the interface to which it is connected. Termination is generally not required in lower speed networks (9600 baud or less) and networks shorter than 500 m in length. No more than 2 termination resistors should be used, one at each end of the RS485 transmission line.
A baud rate of 4800, 9600, 19200, 38400, 56800 or 115200 needs to be selected using the Baud Rate option. Other settings, including the number of bits, odd or even parity and 1 or 2 stop bits are added in the Settings field. The most common setup is 8 bits, no parity and 1 stop bit or “8N1”.
The serial interface can be configured in serial capture mode or MODBUS mode using the Mode option.
Set Mode to Capture, Modbus or Scripted. In Scripted mode the serial port is controlled entirely from a script.
Capture mode is typically used where an external sensor sends serial data and a portion of that serial data is to be captured. MODBUS mode is used to connect to external sensors that are compatible with the MODBUS standard.
In serial capture mode, the device listens for periodic data and when received, transmits this data at the next send interval. The maximum length of a message that can be captured is 512 characters. Once 512 characters have been received, the ORB-C1 will terminate the capture and will transmit it on the next transmit interval.
In capture mode, the Max Time setting can be used to set a timeout after which the serial port will return to sleep. Max Time can be used as a way to end serial measurement in the event that no serial data is received, or as a mechanism to allow the device to sample the serial port for a defined time-period.
Note
If the serial port needs to be kept on all the time, set the Max Time to longer than the measurement interval. The contents of the serial buffer is retained as long as the device does not return to sleep.
The operation of the Max Chars option is similar to the Max Time setting except that the serial port stops sampling after a certain number of characters has been received. In most cases where the Max Chars setting is used to terminate serial capture, the Max Time setting is also used to end the serial measurement in the event that data does not arrive.
In serial capture mode, in systems where many messages are sent and only a few are of interest, a Start String of up to 10 characters can be enabled. For instance, in a typical GPS serial NMEA feed, the following are a subset of available messages:
DTM - Datum being used.
GGA - Fix information
GLL - Lat/Lon data
GSA - Overall Satellite data
GSV - Detailed Satellite data
RMC - Recommended minimum data for GPS
RTE - Route message
VTG - Vector track an Speed over the Ground
If in the application, the user is only interested in receiving the GGA message, then a Start String can be set to GGA. In that way, any messages starting with DTM, GLL, GSA or other unwanted messages will be discarded.
Note
If a start string is enabled, the device will stay awake until the string is received or until the Max Time is reached.
In firmware revisions less than 2, serial start strings are specified as text, with special characters such as carriage return and line feed being specified by their respective escape sequences. A list of allowable escape sequences is given below:
\f Form-feed
\n Newline (Line Feed)
\r Carriage Return
\t Horizontal Tab
\v Vertical Tab
\\ Backslash
Note
Because escape sequences start with a backslash (\), if a capture string contains a backslash, it needs to be escaped and so is represented as a double backslash (\\).
In firmware release 2 and above, serial start strings are specified as text, with special characters such as carriage return and line feed being specified by their respective ASCII codes in hexadecimal. A list of example hexadecimal sequences is given below:
\x0C Form-feed
\x0A Newline (Line Feed)
\x0D Carriage Return
\x09 Horizontal Tab
\x0B Vertical Tab
\x08 Backslash
The change to the method used to represent special characters has been made to allow for all ASCII characters to be used, and to allow for hexadecimal data to be captured.
Note
In firmware revisions 2 and lower, special characters are specified as escape characters. In revisions 2 and above, special characters are represented by their ASCII representations in hexadecimal.
In some serial protocols, the start of a packet is specified by a preceding period of inactivity on the serial bus. The Idle Time Before Start parameter can be used to specify an idle time, which is exceeded will trigger the serial port to start capturing serial data.
Note
If the serial port is capturing data and a subsequent idle time occurs, the capture process will restart and captured data will be discarded.
A serial capture End String of up to 10 characters can also be provided. Again using the NMEA example, all NMEA messages end with a carriage return and line feed and so the serial capture stop strings in each case will be the same and will be “\r\n” or \x0D\x0A in revision 2 and above firmware. In most instances, the serial stop strings will be the same for all messages.
Note
If a Start String is specified without a End String, or the End String is never encountered, the serial port will capture characters until the Max Time or Max Chars is reached, the next measurement interval occurs or 256 characters are received.
An optional serial Request String can be sent, on each measurement interval, to an external device. The purpose of the Request String is to request data from an external sensor or system. The Request String can be a maximum of 10 characters and can be entered as text. Special characters like carriage return and line feed can be inserted using escape sequences or their ASCII representations as described earlier in the chapter.
The ORB-C1 implements the MODBUS communications protocol standard as a master, which enables communication with many slave devices connected to the network. The ORB-C1 can be configured to periodically request specific data from slave MODBUS devices on the network and transmit that data at specified intervals.
Up to fifty MODBUS data requests can be configured; these can be from individual slave devices or several requests to the same device. Each request is a row in the Modbus table, with a Slave Address, Function and Register Address. The Slave Address is set by the manufacturer of the connected device; some devices allow it to be changed. The Function sets the type of data to be read:
Function |
Reads |
|---|---|
Disabled |
The channel is not used. |
1: Read Coil |
A 1-bit coil. |
2: Read Discrete |
A 1-bit discrete input. |
3: Read Unsigned Holding (16-bits) |
One 16-bit holding register, unsigned. |
4: Read Unsigned Input (16-bits) |
One 16-bit input register, unsigned. |
Read Signed Holding (16-bits) |
One 16-bit holding register, signed. |
Read Signed Input (16-bits) |
One 16-bit input register, signed. |
Read Unsigned Holding (32-bits, … register order) |
Two holding registers as a 32-bit unsigned value. |
Read Unsigned Input (32-bits, … register order) |
Two input registers as a 32-bit unsigned value. |
Read Signed Holding (32-bits, … register order) |
Two holding registers as a 32-bit signed value. |
Read Signed Input (32-bits, … register order) |
Two input registers as a 32-bit signed value. |
Read IEEE-754 Float Holding (32-bits, … register order) |
Two holding registers as a 32-bit floating-point value. |
Read IEEE-754 Float Input (32-bits, … register order) |
Two input registers as a 32-bit floating-point value. |
Read IEEE-754 Double Holding (64-bits, … register order) |
Four holding registers as a 64-bit floating-point value. |
Read IEEE-754 Double Input (64-bits, … register order) |
Four input registers as a 64-bit floating-point value. |
Each 32-bit and 64-bit function is available in Little Endian and Big Endian register order.
Endianness is the order or sequence of bytes of digital data in computer storage and will be specified by the sensor that is being connected to the ORB-C1.
A single MODBUS device may have multiple data values that can be read. The Register Address specifies which data the slave device needs to deliver.
In Modbus mode, calibration can be applied so that the registers read by the ORB-C1 can be scaled to be in the units of what is being measured. For instance, a register that returns 0 to 255 may represent 0% humidity to 100% humidity. The ORB-C1 can be calibrated to take a number and to convert it to humidity in % and return that as the measured value.
In any system, the sensor and possibly the measured value will be subject to errors that may accumulate to reduce accuracy. In a system that uses the ORB-C1 to measure fluid volume in a 100 litre tank using a MODBUS sensor, the sensor may have offset errors such that with zero liquid in the tank, the ORB-C1 is showing a small volume. The ORB-C1 and sensor may also not be perfectly linear in that they may not measure 1 litre in exactly the same way when the tank is empty versus when it is full. The tank itself may also not be perfectly manufactured and may, for instance have walls that are not perfectly straight. All of these errors could add together such that the final system is less accurate than expected. To achieve a more accurate system, a calibration can be performed. In this example, the tank could be calibrated by adding a small amount of liquid, say 10 litres (low Y) and noting the value reported by the ORB-C1 (low X). Now fill the tank by adding another 99 litres (high y) and note the value being reported by the ORB-C1 (high X). By filling the high and low X and Y values into the calibration for that MODBUS channel, offset and non-linearity errors can be eradicated, resulting in a much more accurate system.
In Modbus mode, warning and alarm thresholds can be set for each MODBUS channel. Once enabled, each time a measurement is completed, the returned value will be compared with minimum and maximum warning and alarm thresholds. If a warning or alarm level is breached, a message will immediately be transmitted. As long as the warning or alarm condition persists, messages will be transmitted at the exception-interval rather than the transmit-interval.
Note
If calibration has been applied, then the warning and enable thresholds are in the calibrated units.
A full list of serial interface settings is given in the table at the end of the chapter.
Inputs
Pins 8 and 9 on the 12 way header are multi-purpose inputs. The inputs can be configured to measure analog voltages, where the value on the pin is measured; digital states that represent ON or OFF; frequency; duty cycle and count pulses. In analog and digital mode, pin 8 represents input 1 and pin 9 represents input 2.
Pin |
Channel |
|---|---|
8 |
Input 1 |
9 |
Input 2 |
The voltage present on the inputs should not exceed 72 V. The inputs are protected against over-voltage events to 100 V and against static discharge.
The equivalent input impedance of pins 8 and 9 is the same and is shown below. As far as DC circuits are concerned, any input connected to pin 8 or 9 will experience a 310kΩ resistance to ground. For analog measurements, a low-pass filter reduces high frequency noise, improving measurement accuracy.
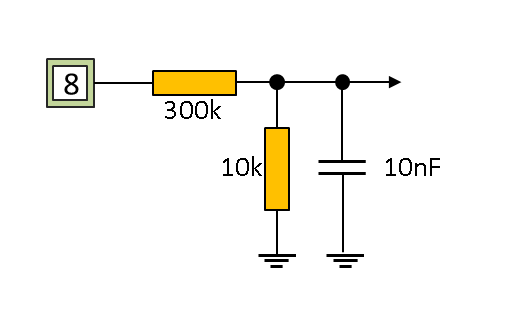
Equivalent circuit for inputs
Note
The low pass filter is not applied when the input module is used to measure frequency and duty cycle.
Specification
Parameter for Analog and Digital measurements |
Specification |
|---|---|
Maximum input voltage |
72 V |
Analog measurement accuracy |
+-50mV |
Input resistance (Input1) |
182kΩ |
Input resistance (Input2) |
310kΩ |
Input filter cutoff frequency |
53 Hz |
Parameter for Frequency and Duty Cycle Measurement |
Specification |
|---|---|
Maximum input voltage |
72 V |
Input resistance (Input1) |
182kΩ |
Minimum amplitude |
3 V (measured down to 1.7 V but not guaranteed) |
Minimum measureable frequency |
1 Hz (square wave, 3 V minimum amplitude) |
Maximum measureable frequency |
10 kHz (square wave, 3 V minimum amplitude) |
Frequency measurement resolution |
1 Hz |
Frequency measurement accuracy |
+-1Hz to 100 Hz, +-10Hz to 10 kHz |
Maximum measurable duty cycle |
100% |
Minimum measureable duty cycle |
1% |
Duty cycle measurement resolution |
1% |
Duty cycle accuracy |
+-1% |
Minimum pulse duration for duty cycle measurement |
10msec (1% of 1 Hz) |
Parameter for Pulse Counting |
Specification |
|---|---|
Maximum input voltage |
72 V |
Input resistance (Input1) |
182kΩ |
Minimum amplitude |
3 V (tested down to 1.7 V but not guaranteed) |
Minimum frequency |
0.01 Hz (not tested lower) |
Maximum measureable frequency |
5 kHz (square wave, 3 V amplitude) |
Minimum pulse duration for pulse counting |
+100usec (tested to 20usec but not guaranteed) |
Settings
Measurements can be scheduled as a multiple of the base-interval. The fastest possible measurement rate is achieved by setting the Interval to 1 in which case measurements will occur on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the Interval.
The mode selects the function of the input pin. Input 1 can be operated in Digital, Analog, Frequency and Duty Cycle modes; input 2 only has Digital and Analog modes.
Analog mode
Select analog mode if the input is a voltage that needs to be measured. Analog measurement should be used when interfacing with voltage-output sensors or when measuring a voltage, for instance when reporting on solar capacity. The maximum voltage that can be measured is 72 V and the resolution is 50 mV.
For maximum accuracy, and to allow for scaling of sensors, calibration can be applied in analog mode.
Digital mode
Select digital mode if the input typically has two levels and can be considered as ON or OFF. Digital mode is typically used when interfacing to a switch or a system that has two discrete voltages representing ON and OFF. An example of a signal with 2 discrete on and off voltage levels would be an ignition signal on a vehicle. In digital mode, the threshold at which an input is considered ON or OFF can be set between 0 and 72 V in 100 mV increments. For example, if the ORB is being used to detect an ignition signal in a 12 V vehicle, the threshold could be set to 6 volts. In a system where the output is either 0 or 5 volts, the threshold could be set at 2.5 volts. Hysteresis can be applied to prevent false changes in state if the input voltage crosses the threshold slowly or in the presence of noisy inputs. In the example below, adding hysteresis prevents the output falsely showing as on as the noisy signal crosses the threshold. In digital mode, the hours that the input is above the threshold can be counted and used as an hour meter.
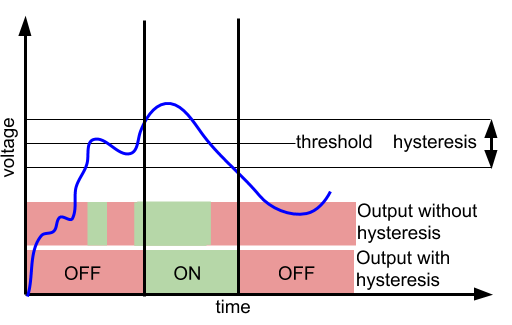
Hysteresis
Since the inputs on the ORB have a 310kΩ resistance to ground, if an external switch is placed between supply and the input, no additional circuitry is required. When the external switch is open, the 310k resistance will pull the input low. When the external switch is closed, the input will be driven high. Where there is no permanent power source, switches can be powered using one of the current loops. Connection to an external switch that is connected to system power is shown below.
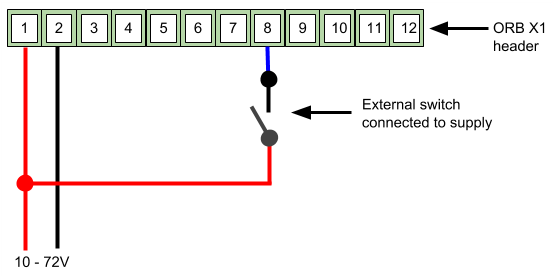
External switch connection when switch to positive
If an external switch is to be connected to ground, an external pullup resistor of less than 10kΩ is required between the pin to which the switch is connected and system power. Power to the pullup can also be provided using the internally generated switched power on either of the current source pins. When the switch is open , the external pullup drives the pin high. When the switch is closed, the pin is grounded. Connection to an external switch that is connected to ground is shown below.
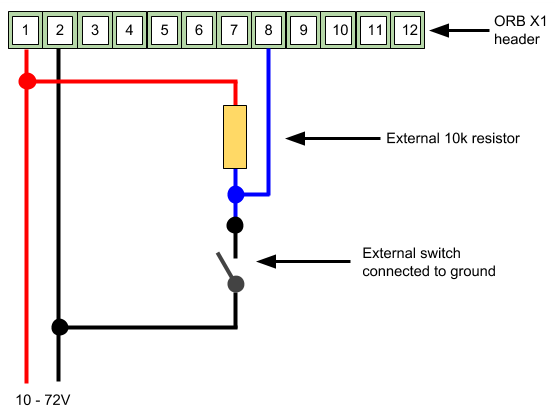
External switch connection when switch to ground
Note
Connecting an external pullup resistor will increase current consumption when running of batteries and using the switched power output.
In digital mode, an alert can be generated when the input changes state. This may be useful, for instance where monitoring an alarm system to see if it is activated or not. Each time the system is activated or de-activated, an alert can be generated and transmitted
Input 1 has additional functionality that allows switch change of state detection whilst the ORB is in sleep state. This allows the ORB to remain in a very low power sleep state, to wake on switch level change and transmit the change of state. This functionality is not available on input 2.
Frequency mode
Input 1 has an additional mode that allows for the measurement of frequency. In frequency mode, on each measurement interval, the frequency of a signal on the pin is measured. Primary applications are speed, rpm and flow rate measurement.
In the diagram below, the ORB is configured to measure engine speed using an output from the P (pulse) terminal on an alternator.
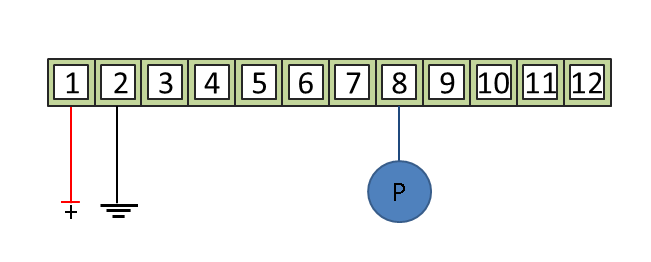
RPM measurement
Duty-Cycle mode
Input 1 has an additional mode that allows for the measurement of duty-cycle. In duty-cycle mode, on each measurement interval, the duty-cycle of a signal on the pin is measured. Sensors regularly use duty cycle to communicate percentage of full-scale; for instance, 0% duty cycle may represent 0% humidity and 100% duty-cycle may represent 100% humidity. In some sensors, 0% and 100% duty cycle represent error conditions.
Calibration
In analog mode, frequency mode and duty-cycle mode, calibration can be applied so that the measurement returned by the ORB is in the units of what is being measured. For instance, in analog mode, a voltage of 0 to 5 V may represent 0% humidity to 100% humidity. The ORB can be calibrated to take a voltage measurement and to convert the measurement to humidity in % and return that as the measured value.
In any system, the measurement instrument (the ORB), the sensor and possibly the measured value will be subject to errors that may accumulate to reduce accuracy. In a system that uses the ORB to measure fluid volume in a 100 litre tank using a 4-20 mA sensor, the ORB and sensor may have offset errors such that with zero liquid in the tank, the ORB is showing a small volume. The ORB and sensor may also not be perfectly linear in that they may not measure 1 litre in exactly the same way when the tank is empty versus when it is full. The tank itself may also not be perfectly manufactured and may, for instance have walls that are not perfectly straight. All of these errors could add together such that the final system is less accurate than expected. To achieve a more accurate system, a calibration can be performed. In this example, the tank could be calibrated by adding a small amount of liquid, say 10 litres (low Y) and noting the value reported by the ORB (low X). Now fill the tank by adding another 99 litres (high y) and note the value being reported by the ORB (high X). By filling the high and low X and Y values into the calibration constants associated with analog mode, offset and non-linearity errors can be eradicated, resulting in a much more accurate system.
Warnings and Alarms In analog mode, frequency mode and duty-cycle mode, warning and alarm thresholds can be set. Once enabled, each time a measurement is completed, the returned value will be compared with minimum and maximum warning and alarm thresholds. If a warning or alarm level is breached, a message will immediately be transmitted. As long as the warning or alarm condition persists, messages will be transmitted at the exception-interval rather than the transmit-interval.
Note
If calibration has been applied, then the warning and enable thresholds are in the calibrated units.
Pulse counting
In all modes, the number of pulses that have occurred since the ORB was last reset can be measured and reported. To count pulses, turn on Pulse Counting. If for instance, a flow-sensor is being used to deliver fuel to a vehicle, the instantaneous frequency would represent flow rate (possibly in litres per minute) and the number of pulses would represent the total amount of fuel delivered (possibly in litres). When pulse counting is turned on, the ORB remains awake, continuously monitoring the input in order to capture all the pulses that occur.
Note
In firmware releases from SFW002-3.0.0, the pulse count is stored to non-volatile memory and so will be retained during a device reset.
The count can be set to reset after a number of pulses have been counted, using Reset Value. This may be useful, for instance if a sensor is measuring water in litres, and only kilolitre indications are required. In this case, a Pulse Warning level can be set at 1000 pulses at which time a transmission will be made and at the same time, the counter will be reset. One transmission will be made for each 1000 litres of water measured.
Note
Because pulse counting keeps the input active, there will be an increase in power consumption.
In the diagram below, a flow sensor with integrated reed-switch is connected to input 1 to allow the number of pulses occurring to be measured.
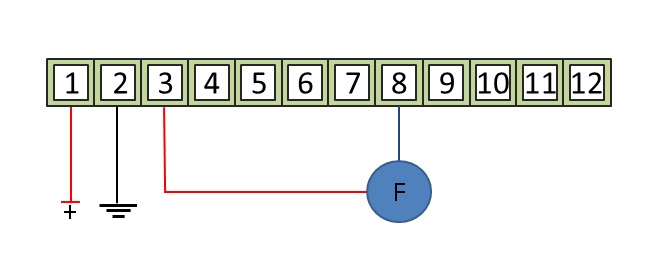
Flow sensor connection
A full list of settings for the inputs is given in the table at the end of this chapter.
CAN Bus interface
The Senquip ORB-C1 is equipped with CAN bus that can be used to read data from all kinds of vehicles and sensors. Many sensors, controllers, and electronic devices can be connected to a single CAN network.
In many cases, the protocol that is being used on the CAN bus is known, and so large volumes of understandable data can be extracted from all kinds of vehicles. Common CAN protocols include:
J1939, the dominating CAN-based protocol for trucks and busses.
ISO 11783, a J1939 flavor for agricultural tractors.
ISO 11992, an interface between trucks and trailers.
NMEA 2000, a protocol based on J1939 for marine use.
CANopen, provides a standard for industrial machinery commonly used in industrial automation.
The CAN interface on the ORB-C1 supports Classical CAN and CAN FD (Flexible Data-rate). Pins 11 and 12 are for the CAN1 interface with pin 11 being CAN High (dominant high) and pin 12 being CAN Low (dominant low).
Pin |
Function |
|---|---|
11 |
CAN1 H |
12 |
CAN1 L |
In CAN networks, 120Ω termination resistors are installed at each end of the network. In most installations, the required termination will already be present and the internal termination resistor should remain disabled. If the ORB-C1 is located at the end of a CAN network and termination is required, the internal termination resistor can be enabled in the CAN settings. No external termination resistor is required.
Warning
In CAN bus systems, the ground supplied to the Senquip ORB-C1 must be the same ground as used by the CAN network. High differential voltages between the CAN lines and ground can damage the CAN interface.
Specification
Parameter |
Specification |
|---|---|
CAN physical layer |
High-speed CAN (ISO 11898-2 compatible) |
Supported protocols |
Classical CAN and CAN FD |
Maximum Classical CAN bit rate |
1Mbit/s |
Maximum CAN FD data rate |
4Mbit/s |
Bus fault protection on CAN High and CAN Low |
+/-60V |
ESD protection, CAN bus pins |
+/-25kV |
Termination resistor |
120Ω |
Settings
Measurements can be scheduled as a multiple of the base-interval. The fastest possible measurement rate is achieved by setting the Interval to 1 in which case the CAN network will be sampled on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the Interval.
The CAN bus peripheral on Senquip devices supports can bit rates of 125kbit/s, 250kbit/s, 500kbit/s and 1Mbit/s as specified in the Nominal Baud Rate field.
Configurable internal 120Ω termination resistors can be enabled.
To ensure minimum intrusion on CAN systems, the CAN peripheral can be set to listen only. In this mode the Senquip device will only receive messages that are acknowledged on the bus by a listening node. Where required, the Senquip device can be made to acknowledge messages by selecting the TX Enable option.
The Capture Time setting can be used to set a timeout after which the CAN bus peripheral will stop listening, allowing the Senquip device to transmit received messages and return to sleep. capture-time can also be used as a mechanism to allow the CAN peripheral to sample the CAN bus for a defined time-period.
A full list of CAN bus settings is given in the table at the end of this chapter.
CAN Filters
Most automotive CAN networks transmit hundreds of different messages, each with a unique identifier. The Senquip device allows you to filter and capture only the messages you need using the ID Capture List.
Basic Usage
Enter the CAN IDs you want to capture in hexadecimal, separated by commas. For example:
18FF20F2,18FF36F0,18FF1BF2
During each measurement interval, the device listens for the listed messages until either all are received or the Capture Time expires.
Capturing Multiple Messages
To capture multiple messages with the same ID, use * followed by the number of each message required:
18FF20F2*4,18FF1BF2*10
This captures:
4 messages with ID
18FF20F210 messages with ID
18FF1BF2
To capture all messages of a certain ID received during the interval, use * without a number:
18FF1F12*
Special Cases
Leave the list
blankto capture one of every message that arrives.Use a single
*to capture all messages, in the order they arrive.Warning
Capturing all messages may overwhelm the device in high-traffic CAN systems. The number of messages that can be captured in a measurement cycle is internally limited to 128.
Limits
Up to 128 messages are captured in each measurement cycle.
The ID Capture List can be up to 200 characters long.
Sending CAN Messages
CAN messages can be sent to connected device from within a script. The messages can be sent once, or can be set to repeat at a given time interval. If the device enters sleep or hibernate, repeating messages will be stopped. If the Senquip device is reset, the sending of repeating CAN messages is unaffected. The messages will continue to be sent until a change is applied. For example, if new script is loaded, forcing a reset, the CAN messages will continue to be sent until the new script applies a change. In the case of a malfunction that lasts for more than 30 second, repeating CAN messages will be stopped.
Note
To send CAN messages, the TX Enable option must be selected.
Output
An open-collector output that can be made to switch to ground is provided on pin 10 of the header. The output is capable of sinking 450 mA to ground and has an internal resettable fuse in place to prevent over-current events. The output is capable of switching coils and is therefore able to drive external relays and low power solenoids. The open circuit voltage applied to the output should not exceed system voltage or 72 V.
As an alternate function, where additional inputs are required, the output can be configured as an analog or digital input.
Note
There is a limit to the amount of energy that the protection circuit can absorb. For instance, shorting the output to power at 72 V when the output is on will likely destroy the output.
The output is typically used to indicate warning and alarm conditions currently active and can be set to active in the event of a measurement returning an exception. When configured to do so, the buzzer or indicator lamp shown in the diagram below will turn on when a warning or alarm condition exists as pin 10 is switched to ground.
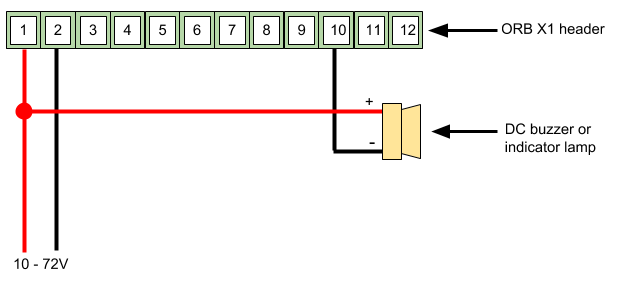
Using the output to drive a buzzer with permanent power
In solar or battery operated systems where permanent power is not available, externally powered current output sensors can utilise the ORB switched power source on pin 3 as shown below.
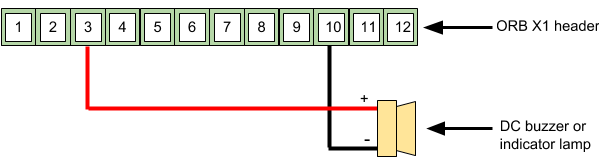
Using the output and internal power to drive a buzzer
Specification
Parameter |
Specification |
|---|---|
Maximum open circuit voltage |
72 V |
Maximum hold current |
450 mA min |
Minimum fuse current |
550 mA max |
Digital input threshold |
6 V |
Hysteresis |
1 V |
Settings
The output can be scheduled to be configured at a multiple of the base-interval. In the event that the Interval is set to a number higher than 1, the output state will only checked and configured on the next output interval. This can be used to create a pulsed output that may be useful in driving alert indicators or in allowing attached devices to time to cool down.
The Mode setting can be used to configure the output with alternate functions as an analog or digital input. In input mode, the same settings as are associated with Input 2 apply except that the digital threshold and hysteresis are fixed.
The output can be configured to activate when any of the peripherals report an exception (warning, alarm or alert) as a result of a measurement and can be set to remain on only as long as the warning or alarm is active or to hold on for the Hold Time after the warning or alarm has gone away.
Note
The output state will be configured at each output interval. The hold-time is how long the output is kept enabled after the exceptions are cleared.
A full list of settings for the output is given in the table at the end of this chapter.
Calibration
Calibration can be applied to each measurement so that the value returned by the Senquip ORB-C1 is in units that are meaningful in the end application. For instance, a fuel level sensor that outputs a voltage between 0 and 5 V may represent a level between 0 and 100 litres of diesel. The voltage measurement can be calibrated to convert from Volts to the more meaningful unit of litres.
In any system, the measurement instrument (the Senquip ORB-C1), the sensor and possibly the measured value will be subject to errors that may accumulate to reduce accuracy. In a system that measures fluid volume in a 100 litre tank using a 4-20 mA sensor, offset errors may result in a non-zero or negative reading when the tank is empty. Sensor gain may also not be perfectly linear and so a 1 litre change may be measured differently when the tank is empty versus when it is full. The sensor may report in inches of liquid height where a more meaningful unit may be litres. To achieve an accurate and meaningful measurement, a calibration can be performed.
In this example, the tank could be calibrated by adding a small amount of liquid, say 10 litres at which point the current measured may be 4.1 mA. Now add more liquid to take the level to say 80l. The sensor now reads 16.2 mA. The calibration would then be filled into the IO setting as shown below:
Low In |
4.1 |
This is the value in mA measured by the Senquip ORB-C1 |
Low Out |
10 |
This is the actual value that we would like to report |
High In |
16.2 |
This is the value in mA measured by the Senquip ORB-C1 |
High Out |
80 |
This is the actual value that we would like to report |
Unit |
l |
The unit to be reported is litres |
Unit Names and Symbols
The calibration Unit field supports plain text together with a number of commonly used engineering symbols. This allows measurements to be displayed using familiar units such as °C, m³, Ω, µS/cm and N·m.
The following characters are supported:
Letters: a-z, A-Z
Numbers: 0-9
Symbols: /, Ω, ·, µ, Δ, ±, ×, :, °, ², ³, ., %, _, -
Examples:
Unit |
Description |
|---|---|
V |
Volts |
A |
Amps |
°C |
Degrees Celsius |
°F |
Degrees Fahrenheit |
Ω |
Ohms |
kΩ |
Kilohms |
m³ |
Cubic metres |
m² |
Square metres |
µS/cm |
Microsiemens per centimetre |
N·m |
Newton metres |
kg/m³ |
Density |
%RH |
Relative humidity |
L/min |
Litres per minute |
When entering units on Windows, some special characters can be entered using their ALT codes on the numeric keypad.
Character |
Windows ALT Code |
|---|---|
° |
|
² |
|
³ |
|
µ |
|
± |
|
× |
|
The remaining symbols can be copied directly from this guide or inserted using the Windows Character Map (charmap.exe) or the Windows Emoji & Symbols panel(Win+.).
Character |
Description |
|---|---|
Ω |
Ohm |
Δ |
Uppercase Delta |
· |
Middle dot |
Warnings and Alarms
Each measurement has one alert setting. It is made up of an Alert Type, a Low Threshold, a High Threshold and a Hysteresis. Each time a measurement is completed, it is compared with the thresholds. If it is at or below the low threshold, or at or above the high threshold, an event of the selected type is raised and a message is transmitted immediately. While the event stays active, messages are transmitted at the Exception Interval.
Alert Type |
Result when a threshold is crossed |
|---|---|
Disabled |
No event. The thresholds are ignored. |
Info |
Event recorded in the device event history; no badge on the Senquip Portal. |
Alert |
Event shown with a blue indicator. |
Warning |
Event shown with an orange indicator. |
Alarm |
Event shown with a red indicator. |
The same alert type applies to both thresholds. To check only one threshold, leave the other one blank. For example, for a high-only warning at 50 V, set Alert Type to Warning, leave Low Threshold blank and set High Threshold to 50.
Some alerts, such as the light sensor’s Tamper Alert, have no thresholds: choose the alert type for the event only.
For how each alert type is shown and forwarded by email or SMS, see Exceptions.
Note
If calibration has been applied, set the thresholds in the calibrated units.
Hysteresis
Hysteresis prevents repeated alarms when a measured value fluctuates near a threshold. The hysteresis value is applied on both sides of the configured threshold. For an upper alarm, the value must reach upper threshold + hysteresis to enter the alarm state, then fall to upper threshold - hysteresis to clear it. For a lower alarm, the value must fall to lower threshold - hysteresis to enter the alarm state, then rise to lower threshold + hysteresis to clear it. Between the two switching points, the alarm retains its current state. Hysteresis uses the measurement configured units.
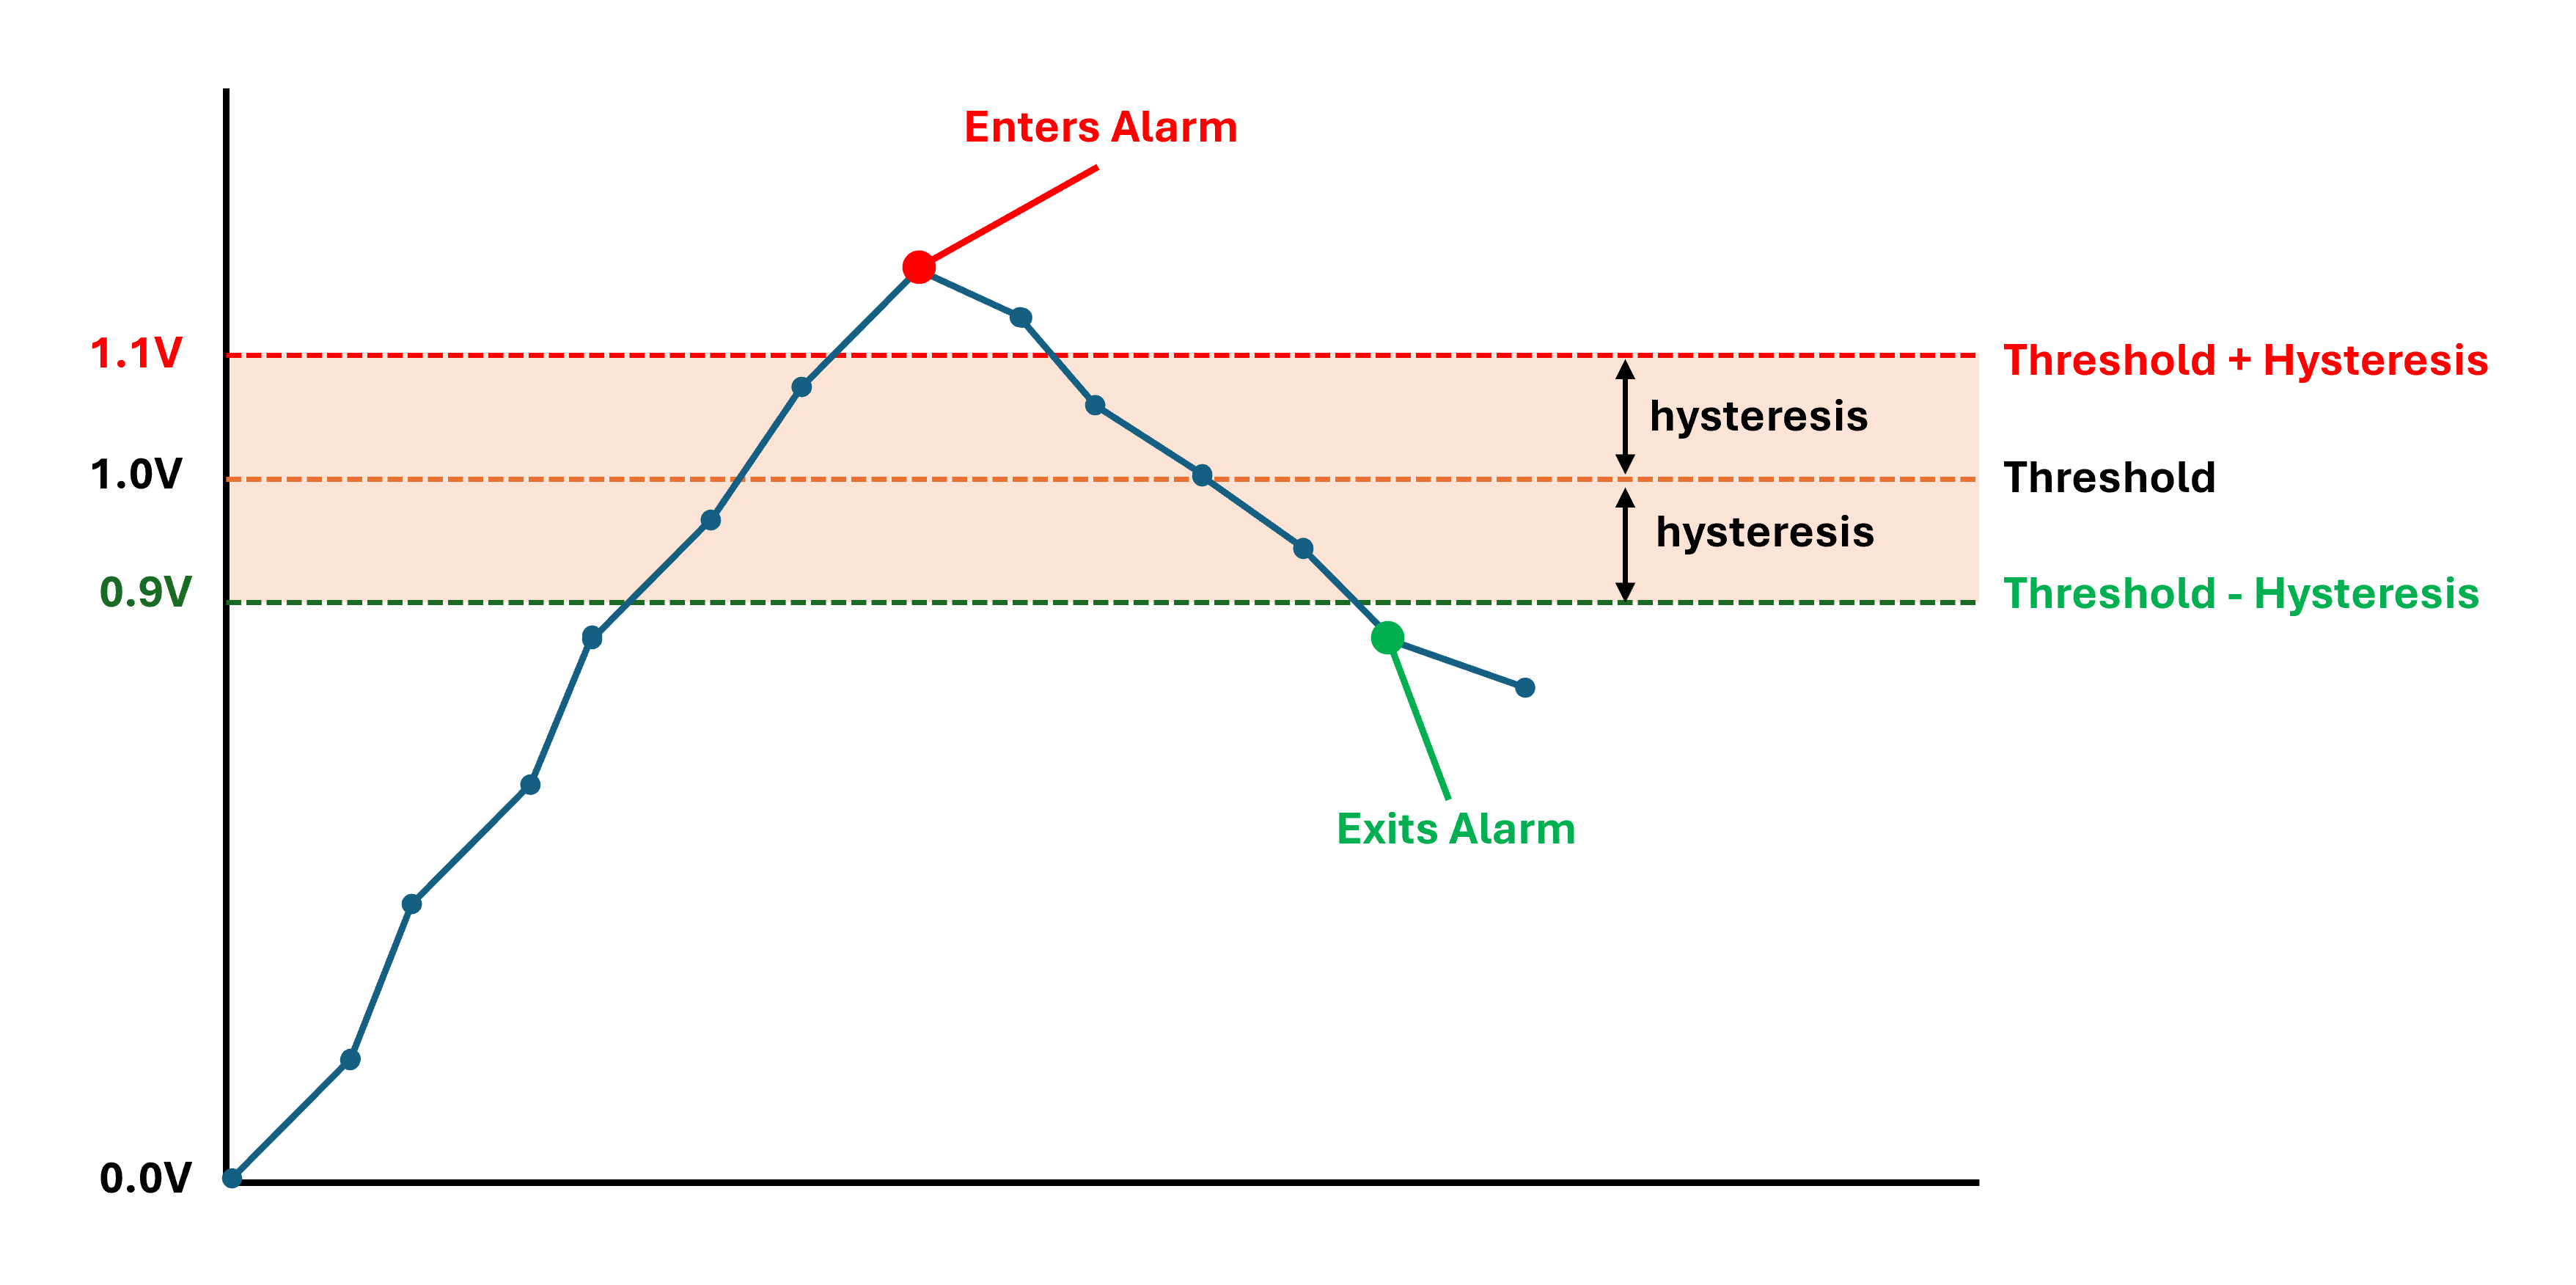
Upper alarm with a 1.0 V threshold and 0.1 V hysteresis. The alarm starts when the measured value reaches 1.1 V and clears when it falls to 0.9 V. Between those values, the alarm retains its current state. Readings shown in red are in alarm.
External Interface Settings
A full list of external interface settings is given in the table below.
Name |
Type |
Description |
Range or options |
Default |
Internal Reference |
|---|---|---|---|---|---|
General IO |
|||||
VSET Voltage |
Decimal |
The voltage setting of the internal voltage supply to IO terminals. |
5 to 25 Volts |
12 |
vset.voltage |
Overcurrent Protection |
On/Off |
Enable overcurrent protection on IO terminals. If enabled, the device will disable the IO if the current exceeds a threshold. |
On |
io.overcurrent_protection |
|
IO1 to IO5 (as fitted) |
|||||
Name |
Text |
A name for the input that is meaningful to the user. |
25 characters |
IO1 |
ioN.name |
Interval |
Integer |
The number of base intervals after which the input is sampled. A value of 1 means that the input is collected every base interval. Set to 0 to disable. |
0 to 10000 |
0 |
ioN.interval |
Wake on Change |
On/Off |
Wake device from sleep/hibernate on digital change. It is recommended to also enable PULLUP mode for this feature. |
Off |
ioN.wake |
|
Default State |
Option |
The state of the output when NOT in an active measurement interval. |
OFF, GND, VIN, VSET, PULLUP |
OFF |
ioN.output.default_state |
Measurement State |
Option |
The state of the output during an active measurement interval. |
No Change, GND, VIN, VSET |
No Change |
ioN.output.meas_state |
Measurement Time |
Decimal |
How long the IO will stay in the Measurement State before measurements are taken. |
0 to 3600 Seconds |
0 |
ioN.output.meas_time |
Measure Digital Input |
On/Off |
Enables digital input measurement on terminal. |
Off |
ioN.digital.enable |
|
Measure Voltage |
On/Off |
Enables voltage measurement on terminal. |
Off |
ioN.voltage.enable |
|
Voltage Calibration |
Calibration |
Calibration parameters. Refer to user guide. |
30 characters Volts |
0,10,0,10,Volts |
ioN.voltage.cal |
Voltage Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
ioN.voltage.alert |
||
Measure Current |
On/Off |
Enables current measurement on terminal. |
Off |
ioN.current.enable |
|
Optimise for 4-20 mA |
On/Off |
Use a lower Full Scale Range (FSR) with higher resolution which is best for 4-20 mA devices. |
On |
ioN.current.low_range |
|
Current Calibration |
Calibration |
Calibration parameters. Refer to user guide. |
30 characters mA |
0,10,0,10,mA |
ioN.current.cal |
Current Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
ioN.current.alert |
||
Measure Frequency |
On/Off |
Enables frequency measurement on terminal. |
Off |
ioN.freq.enable |
|
Frequency Calibration |
Calibration |
Calibration parameters. Refer to user guide. |
30 characters Hz |
0,10,0,10,Hz |
ioN.freq.cal |
Frequency Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
ioN.freq.alert |
||
Measure Duty Cycle |
On/Off |
Enables duty cycle measurement on terminal. |
Off |
ioN.duty.enable |
|
Duty Cycle Calibration |
Calibration |
Calibration parameters. Refer to user guide. |
30 characters Percent |
0,10,0,10,Percent |
ioN.duty.cal |
Duty Cycle Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
ioN.duty.alert |
||
Measure Pulse Count |
On/Off |
Enables pulse count measurement on terminal. |
Off |
ioN.pulse.enable |
|
Pulse Count Calibration |
Calibration |
Calibration parameters. Refer to user guide. |
30 characters Counts |
0,10,0,10,Counts |
ioN.pulse.cal |
Pulse Count Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
ioN.pulse.alert |
||
CAN 1 |
|||||
Name |
Text |
A name that is meaningful to the user. |
25 characters |
CAN 1 |
can1.name |
Interval |
Integer |
The number of base intervals after which the CAN module is turned on. Set to 0 to disable. |
0 to 10000 |
0 |
can1.interval |
Nominal Baud Rate |
Integer |
Baud rate for CAN communication. Supported values are: 125, 250, 500, 1000 |
250 |
can1.nominal_baud |
|
CAN FD Mode |
Option |
Select CAN FD mode. |
Classic, CAN FD, CAN FD BRS |
Classic |
can1.frametype |
Capture Time |
Integer |
The device will capture matching messages for this length of time. |
2 |
can1.capture_time |
|
TX Enable |
On/Off |
Allows the device to transmit and acknowledge messages on the CAN bus. |
Off |
can1.tx_enable |
|
ID Capture List |
Text |
List of IDs to be captured in HEX format, separated by a comma eg: 18FEE60A. Leave blank to capture all. |
200 characters |
can1.id_list |
|
Send Raw Data |
On/Off |
Send all captured data in the standard data message. If unticked, data is only delivered to the scripting handler. |
Off |
can1.send_data |
|
Termination Enable |
On/Off |
Enables termination resistor for the CAN bus. |
Off |
can1.termination |
|
CAN 2 |
|||||
Name |
Text |
A name that is meaningful to the user. |
25 characters |
CAN 2 |
can2.name |
Interval |
Integer |
The number of base intervals after which the CAN module is turned on. Set to 0 to disable. |
0 to 10000 |
0 |
can2.interval |
Nominal Baud Rate |
Integer |
Baud rate for CAN communication. Supported values are: 125, 250, 500, 1000 |
250 |
can2.nominal_baud |
|
CAN FD Mode |
Option |
Select CAN FD mode. |
Classic, CAN FD, CAN FD BRS |
Classic |
can2.frametype |
Capture Time |
Integer |
The device will capture matching messages for this length of time. |
2 |
can2.capture_time |
|
TX Enable |
On/Off |
Allows the device to transmit and acknowledge messages on the CAN bus. |
Off |
can2.tx_enable |
|
ID Capture List |
Text |
List of IDs to be captured in HEX format, separated by a comma eg: 18FEE60A. Leave blank to capture all. |
200 characters |
can2.id_list |
|
Send Raw Data |
On/Off |
Send all captured data in the standard data message. If unticked, data is only delivered to the scripting handler. |
Off |
can2.send_data |
|
Serial 1 |
|||||
Name |
Text |
A name for the input that is meaningful to the user. |
25 characters |
Serial 1 |
serial1.name |
Interval |
Integer |
The number of base intervals after which the serial port is turned on. Set to 0 to disable. |
0 to 10000 |
0 |
serial1.interval |
Type |
Option |
The electrical interface type. |
RS232, RS485 |
RS232 |
serial1.type |
Termination Resistor |
On/Off |
This parameter enables the integrated termination resistor. |
Off |
serial1.termination |
|
Mode |
Option |
Describes how the serial port is to be handled. CAPTURE: serial data is captured between start and end characters. MODBUS: serial data is treated according to MODBUS RTU standard |
Capture, Modbus, Scripted |
Capture |
serial1.mode |
Baud Rate |
Integer |
Baud rate for serial communication. Common values are: 4800, 9600, 19200, 38400, 57600, 115200 |
57600 |
serial1.baud |
|
Settings |
Text |
A string describing the number of bytes: 7,8,9. Parity type: N(none), E(even), O(odd). Number of stop bits: 1 or 2. Typically: 8N1 |
8N1 |
serial1.settings |
|
Capture |
|||||
Start String |
Text |
The serial port starts reading data when it detects these characters. Example: $GPGGA, serial data will be ignored until $GPGGA is received after which data will be captured. If nothing is specified, the serial port will capture all data until the timeout period is reached. |
32 characters |
serial1.capture.start |
|
Idle Time Before Start |
Integer |
For a valid start condition, there must be this amount of idle time before receiving serial data. Additionally, the captured data will restarted if the serial port is idle for this time. Set to 0 to disable. |
0 to 60000 Milliseconds |
0 |
serial1.capture.start_idle_time |
End String |
Text |
Once capturing, if these characters are received, the serial port will stop capturing and will return to sleep. For binary data or escape sequences refer to the User Guide. |
32 characters |
serial1.capture.end |
|
Request String |
Text |
This string will be sent when the serial port is first turned on. Use this function to request data from a remote module. |
32 characters |
serial1.capture.request |
|
Max Time |
Integer |
The device will wait this length of time for a valid capture. |
5 |
serial1.capture.maxtime |
|
Max Chars |
Integer |
Maximum number of characters to be captured before the serial port goes back to sleep. |
to 2000 |
500 |
serial1.capture.maxchars |
Capture Alert |
Alert |
Alert type for this event. See Warnings and Alarms. |
serial1.capture.alert |
||
Modbus RTU |
|||||
Slave Timeout |
Decimal |
How long to wait for a response from each slave device. |
0.1 to 10 Seconds |
0.2 |
serial1.modbus.timeout |
Delay Between Reads |
Integer |
Delay between successive read commands. |
10 to 10000 Milliseconds |
15 |
serial1.modbus.framedelay |