Internal Sensors
Light sensor
The ORB-C1 is equipped with an internal light sensor that is used to activate the setup functions when the lid is opened and to detect tamper attempts. The light sensor is sampled on a regular basis and does not have an associated measurement interval.
An alert can be generated when the lid is opened and the device detects light.
Note
A tamper alert, if enabled will be triggered by a tamper attempt or an authorised entry to change settings.
A full list of light sensor settings is given in the table at the end of the chapter.
Accelerometer
The ORB-C1 contains an integrated 3-axis accelerometer that provides orientation and motion measurements.
The accelerometer can be used to measure:
Pitch
Roll
Tilt
Vibration Level
Although these functions use the same accelerometer, they operate differently and are intended for different applications.
Tilt Measurement
The accelerometer measures acceleration in the X, Y and Z axes. Raw acceleration values are available in G and can be used for custom calculations.
To provide stable orientation measurements, each tilt measurement consists of 10 acceleration samples taken at 1 ms intervals. The average of these samples is used to calculate Pitch, Roll and Tilt.
The X axis passes through the lid of the device, the Y axis passes horizontally through the device and the Z axis passes vertically through the device.
When looking at the front cover, positive pitch is defined as the top of the ORB-C1 tilting towards the observer. Negative pitch is defined as the top of the ORB-C1 tilting away from the observer.
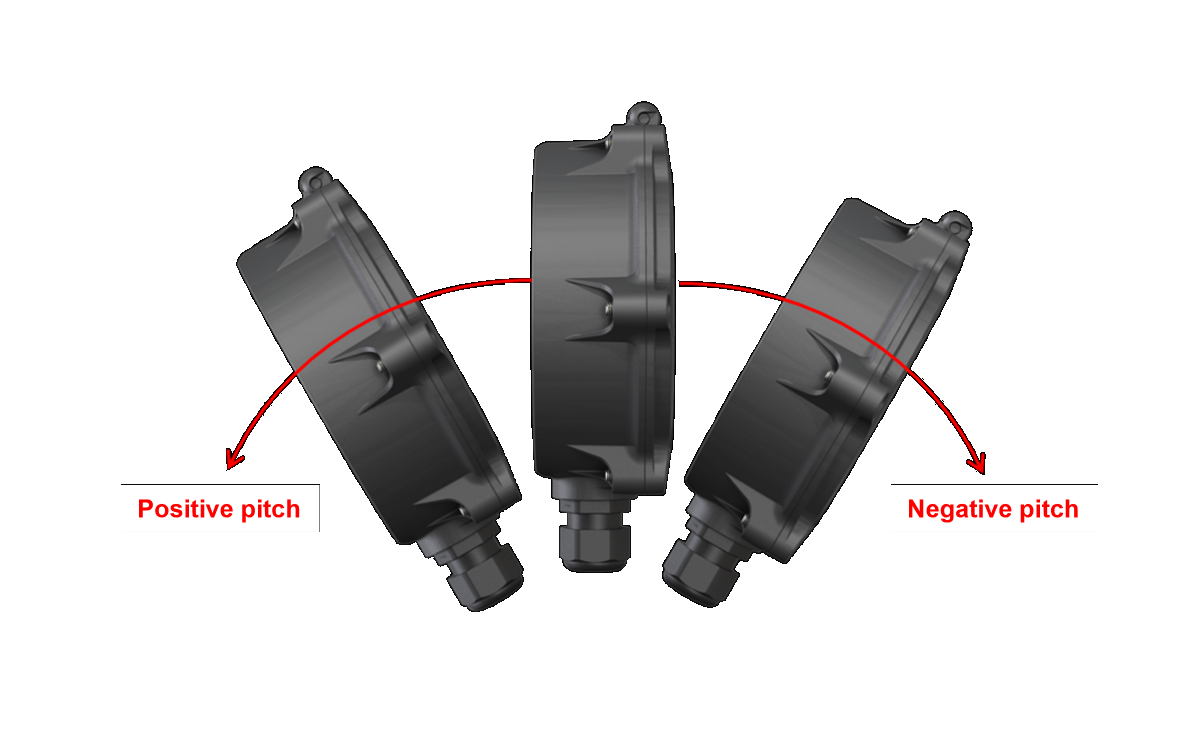
Definition of pitch
When looking at the front cover, positive roll is defined as the top of the ORB-C1 rotating towards the right. Negative roll is defined as the top of the ORB-C1 rotating towards the left.
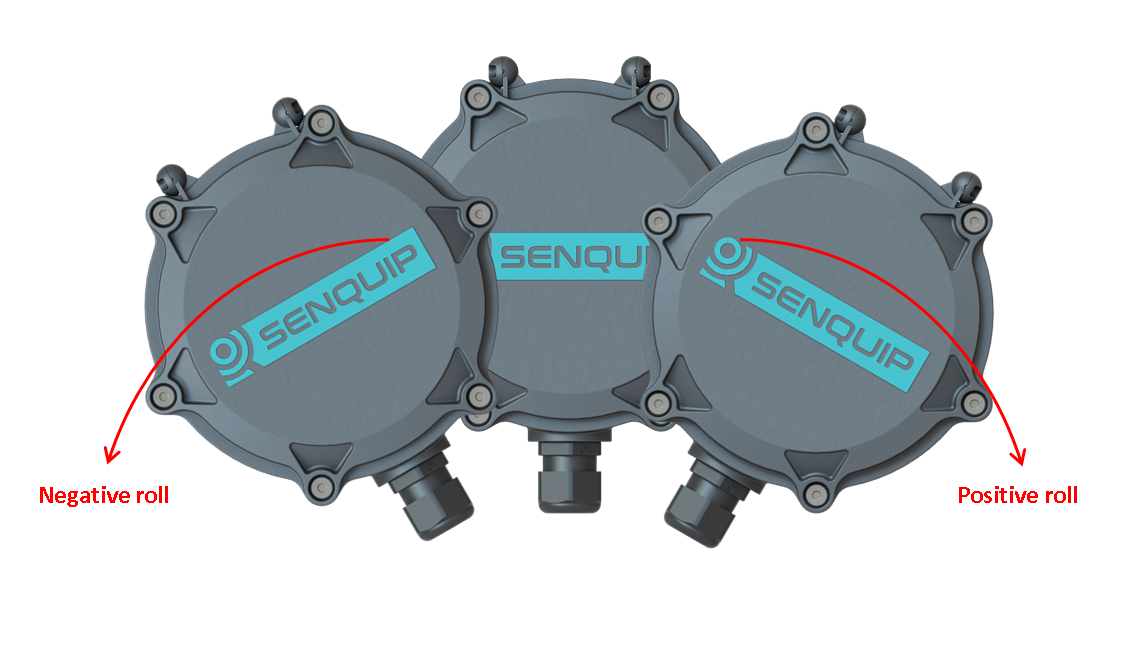
Definition of roll
Pitch and Roll are useful where the monitored object has a defined front, back, left and right, such as a vehicle. For objects such as poles or masts, Tilt is generally more useful.
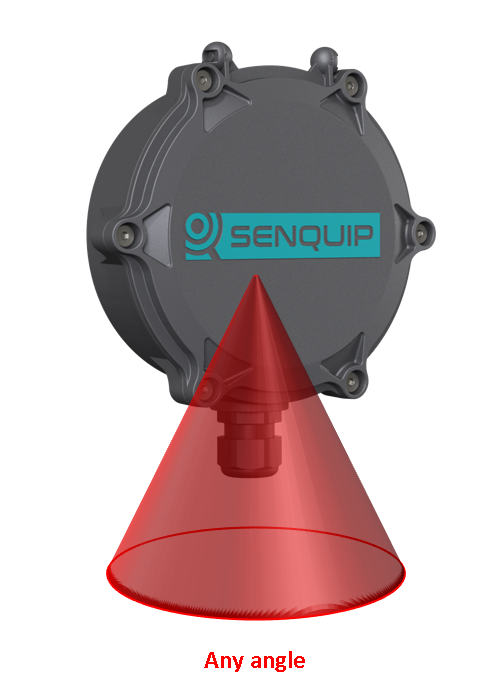
Definition of tilt
Specification
Parameter |
Specification |
|---|---|
G-force range |
+- 2G |
Resolution |
1mG |
Sensitivity change vs temperature |
0.1% per°C |
Typical zero-g level offset accuracy |
+- 40mG |
Tilt resolution |
0.1 deg |
Tilt accuracy (0-45 deg) |
1.0 deg |
Tilt accuracy (45-90 deg) |
2.0 deg |
Settings
Accelerometer measurements can be scheduled as a multiple of the base interval. Setting the Interval to 1 causes measurements to occur every base interval. Increasing the interval reduces power consumption.
Alerts can be set on pitch, roll and tilt. Each time a measurement is completed, it is compared with the low and high thresholds. If either is crossed, an event of the chosen alert type is raised and a message is transmitted immediately, then at the exception interval while the event lasts. See Warnings and Alarms.
Hysteresis can be configured to prevent repeated alerts when measurements fluctuate around a threshold due to vibration.
Note
Pitch and roll thresholds may be positive or negative. Tilt thresholds are always positive.
Vibration Level
The reported Vibration Level provides an indication of the amount of vibration present during the measurement interval. It is intended for long-term condition monitoring, such as detecting increasing vibration caused by bearing wear, imbalance or mechanical deterioration.
Each time a vibration measurement is performed:
The latest 32 acceleration samples are read from the accelerometer.
A statistical variance calculation is performed on the X, Y and Z measurements.
The calculated Vibration Level is reported.
Because only the most recent 32 samples are analysed, the reported Vibration Level represents the vibration at the time the measurement was taken. A short impact that occurs between measurements may not be reflected in the reported value.
Vibration Level is therefore best suited to measuring changes in vibration over time rather than detecting individual impact events.
Choosing the Correct Measurement
Requirement |
Recommended Feature |
|---|---|
Measure orientation |
Pitch, Roll or Tilt |
Monitor machine vibration |
Vibration Level |
Detect long-term vibration trends |
Vibration Level |
Magnetic switch
The ORB-C1 contains a built-in hall-effect sensor that acts as a magnetic switch. When the switch detects a magnet, the ORB-C1 can be made to enter setup mode, wakeup, or trigger a function in a script.
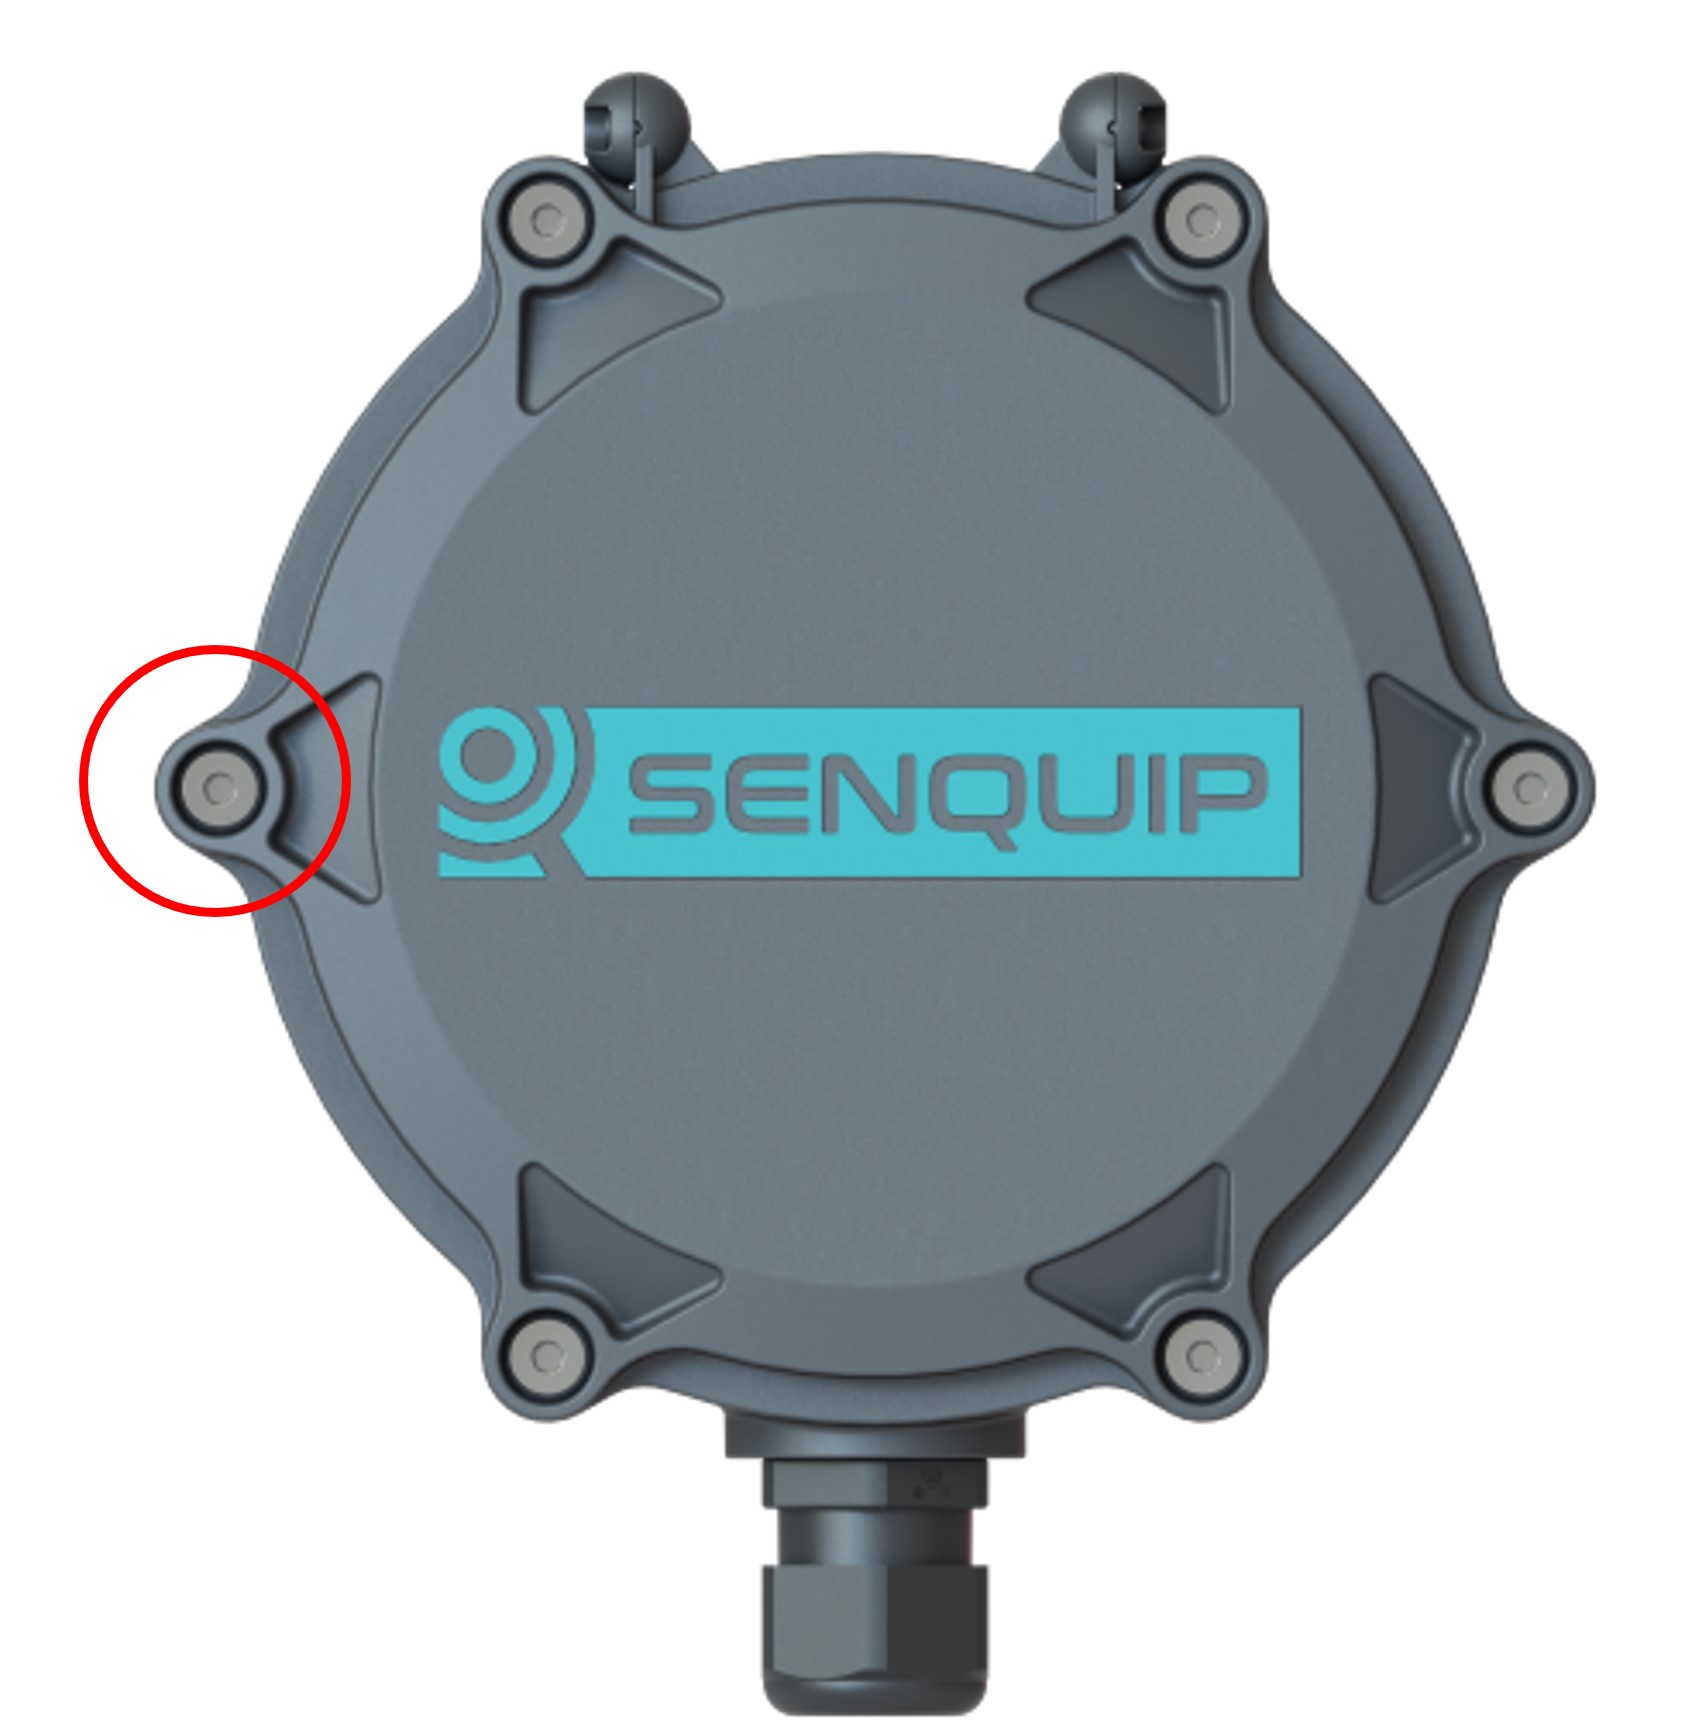
Location of magnetic switch
Settings
Three actions are available when the magnetic switch is activated.
Setup: Put the device into setup mode. Identical to pressing the Setup button. If the device is asleep, it will wake and enter Setup Mode.
Wake: Wake the device up and perform a measurement cycle. There is no action if device is already awake.
Trigger: Wake the device if asleep. Trigger TP0 before first measurement cycle. TP0 should be handled in a script.
Temperature sensor
An integrated temperature sensor allows for measurement of ambient temperature. Please be aware that the temperature sensor will measure the temperature inside the ORB-C1 enclosure; this temperature can be subject to fluctuations, for example when the internal battery is charging and so the environment within the device heats up. For accurate external temperature measurement or to measure a wider range of temperatures, use an external temperature sensor.
Specification
Parameter |
Specification |
|---|---|
Measurement range |
-40 - 85°C |
Resolution |
0.01 deg°C |
Absolute accuracy (25°C) |
+-0.5 deg°C |
Absolute accuracy (0 - 65°C) |
+-1 deg°C |
Settings
Measurements can be scheduled as a multiple of the base-interval. The fastest possible measurement rate is achieved by setting the Interval to 1 in which case measurements will occur on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the Interval.
An alert can be set on the ambient temperature. Each time a measurement is completed, it is compared with the low and high thresholds. If either is crossed, an event of the chosen alert type is raised and a message is transmitted immediately, then at the exception interval while the event lasts. Hysteresis, set in 1°C steps, prevents repeated alerts when the temperature fluctuates near a threshold. See Warnings and Alarms.
A full list of temperature sensor settings is given in the table at the end of the chapter.
GPS
Models of the ORB-C1 that have 4G LTE connectivity also have an integrated Global Navigation Satellite System (GNSS). The GNSS receiver, allows for position and speed based reporting. The internal GNSS received uses GPS, GLONASS, BeiDou and Galileo satellites to ensure high accuracy measurement and fast time to first fix. Data available from the GPS includes:
Latitude, longitude and altitude
Speed (km/h) and bearing
Date and time
Number satellites being tracked
GPS Reception
GPS reception depends on the mounting location and the materials surrounding the device. For devices with internal GPS antennas, the position of the device also determines the position of the antenna.
For best performance, install the device where it has a clear view of the sky. Metal enclosures, electrical cabinets, machine panels and surrounding metalwork can weaken or block GPS signals. Installation inside buildings or deep within machinery may prevent the device from obtaining a position fix.
Plastic enclosures generally have less effect on reception, although surrounding equipment and metalwork can still obstruct signals.
Note
Verify that the device can obtain and update its GPS position at the intended mounting location, with all enclosure doors and machine covers closed. Allow time for the device to obtain its initial fix. Successful reception before installation does not guarantee reliable reception once enclosed.
If reception is inadequate, relocate the device or use a model that supports an external GPS antenna, with the antenna positioned to provide a clear view of the sky.
Specification
Parameter |
Specification |
|---|---|
Time to first fix from power up |
Typically 60 seconds |
Position update rate |
Maximum 1 Hz |
Horizontal position accuracy |
Typically +/-5m (<2.5 m CEP) |
Vertical position accuracy |
Typically +/-20m |
Horizontal speed accuracy |
1 km/h |
GPS/Galileo L1 |
1575.42MHz |
GLONASS L1 |
1602.5625MHz |
BeiDou |
1561.098MHz |
Note
GNSS accuracy is specified as Circular Error Probable (CEP). A specification of <2.5 m CEP indicates that 50% of position fixes will be within 2.5 m of the true position. Typical 95% accuracy is better than 5 m under open-sky conditions.
Settings
Measurements can be scheduled as a multiple of the base-interval. The fastest possible measurement rate is achieved by setting the Interval to 1 in which case measurements will occur on every base interval. To reduce power consumption, the measurement rate can be turned down by increasing the Interval. The GNSS is a high power peripheral and so use should be limited when running on battery power.
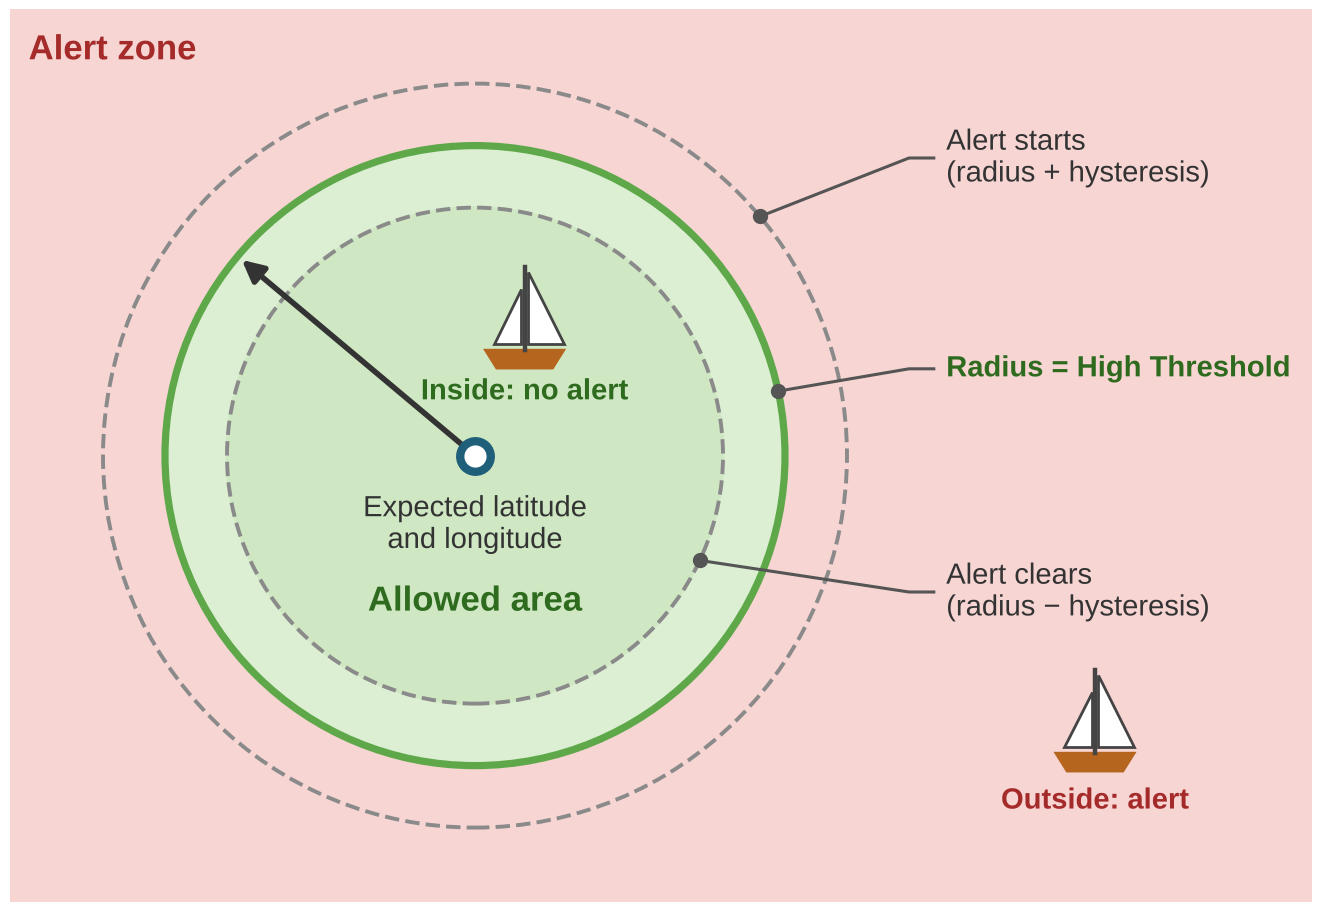
GPS alert parameters
The GNSS can create an alert based on position and speed. A known position (Expected Latitude and Expected Longitude) can be specified and if the device moves a particular Radius from that point, an alert can be raised. Hysteresis can be specified in 1 meter increments to prevent multiple alerts, for instance as a boat swings on a mooring near the edge of the allowed radius. Likewise, a maximum speed can be specified and if the device exceeds that speed, an alert will also be raised. Speed hysteresis can be specified in 1 km/h increments, to prevent multiple alerts as the speed fluctuates at the alert point. The time that GNSS speed exceeds 2 km/h can be counted and used to calculate machine utilisation.
Note
In the example above, the ORB-C1 could also report bilge water level, solar battery voltage and a host of other parameters associated with the yacht.
A full list of GNSS settings is given in the table at the end of the chapter.
Bluetooth interface
The ORB-C1 has a Bluetooth peripheral that can transmit and receive Bluetooth Low Energy (BLE) advertising packets. BLE beacons typically use the advertising packets to communicate measured data such as temperatures, voltages, movement, and battery voltage. BLE tags are a special type of beacon that typically only contain identification information and are used to locate items. BLE beacons send advertising messages at different rates. Some report every second and some may be every minute or more. Battery operated BLE devices tend to send at lower rates to save power. Some BLE device are smart and will slow their send rate if they are not being used. A tire pressure monitoring device may stop sending if the tire is not rotating. Typical protocols used in advertising packets include Eddystone and iBeacon. The ORB-C1 supports both.
The BLE beacons from ELA shown below enable identification, and measurement of temperature, humidity, voltage, switch position, and more.
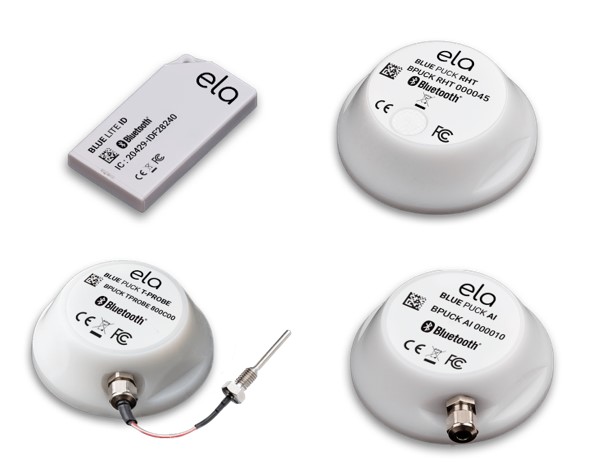
Example BLE beacons from ELA
The ORB-C1 will report the beacon address, data, and the strength of the received signal.
The address (or identifier) is unique and allows individual tags to be recognised.
The data may contain battery voltage, temperature, humidity, or any other data being conveyed by the beacon.
The receive signal strength (RSSI) gives an indication of how strong the signal from the beacon is.
For details on using the ORB-C1 as a BLE beacon to transmit custom advertising packets, please refer to the Senquip Scripting Guide.
Note
The BLE module and Wi-Fi module share a common radio. BLE operation will work best when the ORB-C1 is operated using a cellular network rather than Wi-Fi.
Specification
Parameter |
Specification |
|---|---|
Bluetooth version |
4.2 |
Settings
Enabling Bluetooth
Turn on Enable Bluetooth and set the Interval. The interval is a multiple of the base interval: an Interval of 1 scans on every base interval, and a larger value scans less often to save power. Set it to 0 to turn scanning off. Bluetooth uses RAM, so leave it off if it is not needed.
Scan Time
Each time the Bluetooth peripheral is turned on, it listens for advertising packets for the Scan Time (1 to 300 seconds, 5 by default). The device then sends what it has captured and can go back to sleep. If the Scan Time is equal to or longer than the base interval, the device scans continuously.
Filtering by Address
In a typical environment, phones, computers and other devices are all advertising, so the ORB-C1 could easily report a dozen Bluetooth devices even when the one you want is turned off. Use the Address Capture List to report only the beacons you need.
Enter the addresses in hexadecimal, separated by commas. For example:
98588A10375E,98588A103777
During each scan, the device keeps the first advertising packet received from each listed address.
Capturing Multiple Messages
To capture more than one message from the same address in a scan, add * followed by the number of messages required:
98588A10375E*4,98588A103777,98588A103888*10
This captures:
4 messages from
98588A10375E1 message from
98588A10377710 messages from
98588A103888
Capturing All Beacons
Leave the Address Capture List blank to capture every beacon in range. The device keeps the latest message from each address.
To capture every message in the order it arrives, repeats included, enter a single *:
*
Limits
Up to 20 messages are captured in each scan. Once 20 slots are full, further messages are ignored until the next scan.
The Address Capture List can be up to 200 characters long.
Captured Data
Turn on Send Raw Data to include the captured messages in the standard data message. Each message gives the address (id), signal strength (rssi) and advertising data (data) in hexadecimal. For example:
"ble": [
  {"id": "98588A10375E", "rssi": -67, "data": "0201061AFF4C000215"},
  {"id": "98588A103777", "rssi": -81, "data": "0201060303AAFE"}
]
If Send Raw Data is off, captured messages are passed only to the device script, which can decode them into measurements. See the Senquip Scripting Guide.
A full list of Bluetooth settings is given in the table at the end of this chapter.
Warnings and Alarms
Each measurement has one alert setting. It is made up of an Alert Type, a Low Threshold, a High Threshold and a Hysteresis. Each time a measurement is completed, it is compared with the thresholds. If it is at or below the low threshold, or at or above the high threshold, an event of the selected type is raised and a message is transmitted immediately. While the event stays active, messages are transmitted at the Exception Interval.
Alert Type |
Result when a threshold is crossed |
|---|---|
Disabled |
No event. The thresholds are ignored. |
Info |
Event recorded in the device event history; no badge on the Senquip Portal. |
Alert |
Event shown with a blue indicator. |
Warning |
Event shown with an orange indicator. |
Alarm |
Event shown with a red indicator. |
The same alert type applies to both thresholds. To check only one threshold, leave the other one blank. For example, for a high-only warning at 50 V, set Alert Type to Warning, leave Low Threshold blank and set High Threshold to 50.
Some alerts, such as the light sensor’s Tamper Alert, have no thresholds: choose the alert type for the event only.
For how each alert type is shown and forwarded by email or SMS, see Exceptions.
Note
If calibration has been applied, set the thresholds in the calibrated units.
Hysteresis
Hysteresis prevents repeated alarms when a measured value fluctuates near a threshold. The hysteresis value is applied on both sides of the configured threshold. For an upper alarm, the value must reach upper threshold + hysteresis to enter the alarm state, then fall to upper threshold - hysteresis to clear it. For a lower alarm, the value must fall to lower threshold - hysteresis to enter the alarm state, then rise to lower threshold + hysteresis to clear it. Between the two switching points, the alarm retains its current state. Hysteresis uses the measurement configured units.
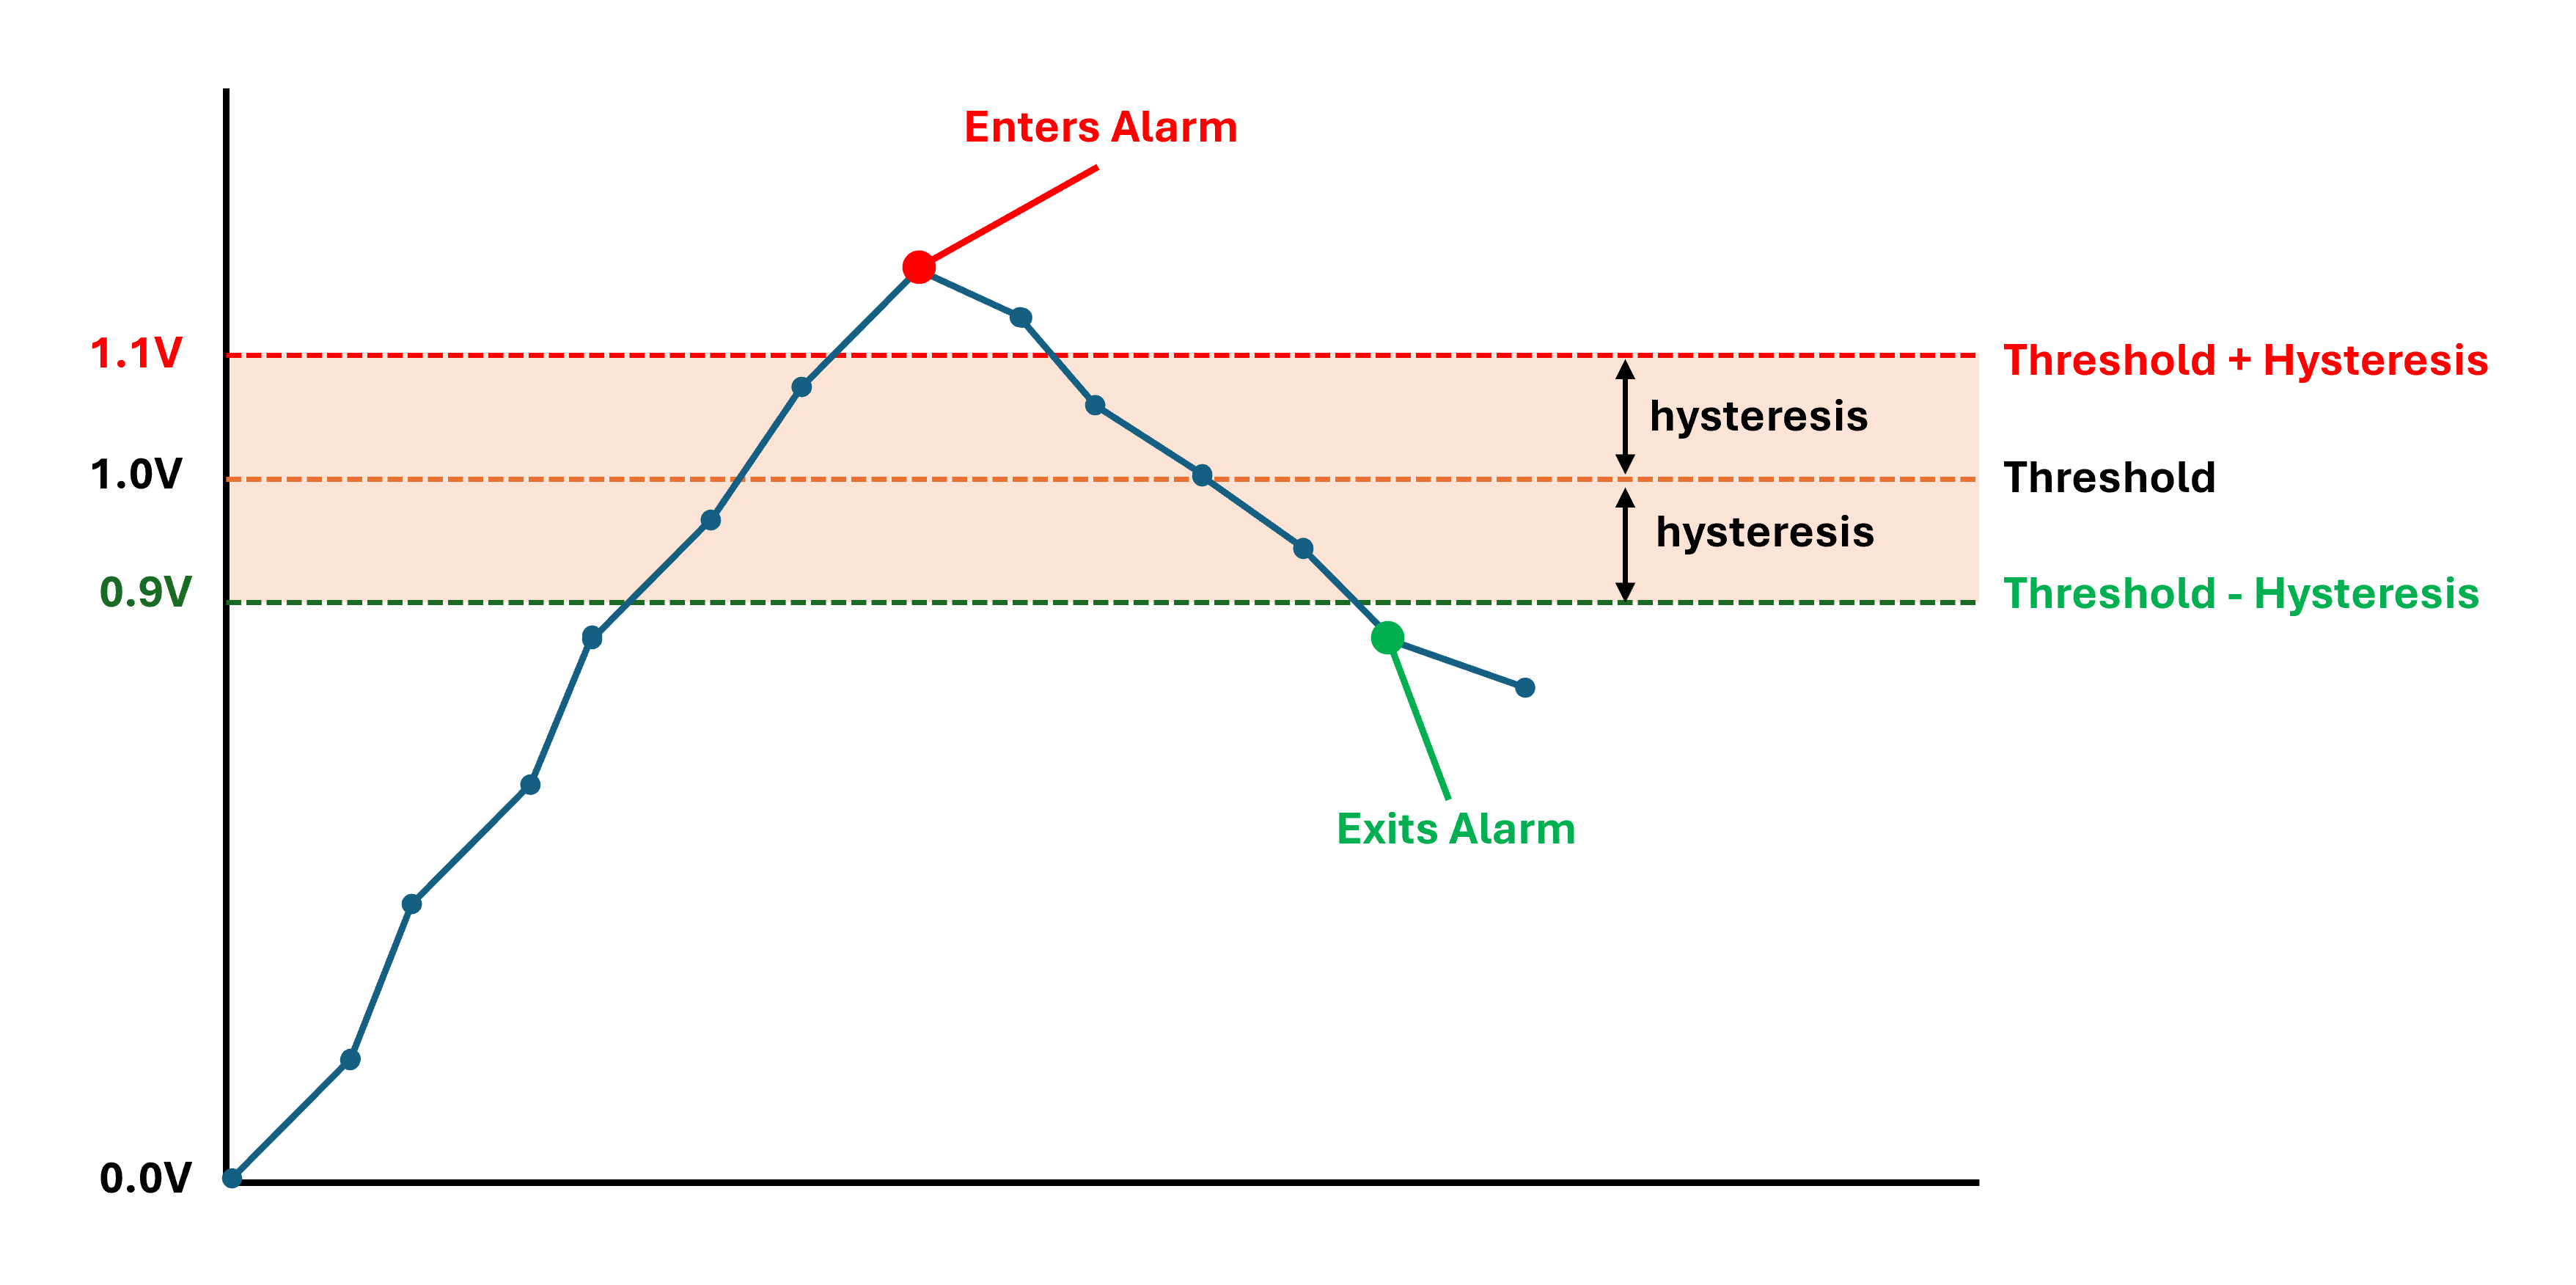
Upper alarm with a 1.0 V threshold and 0.1 V hysteresis. The alarm starts when the measured value reaches 1.1 V and clears when it falls to 0.9 V. Between those values, the alarm retains its current state. Readings shown in red are in alarm.
Internal Sensor Settings
A full list of settings for internal sensors is given in the table below.
Name |
Type |
Description |
Range or options |
Default |
Internal Reference |
|---|---|---|---|---|---|
Light Sensor |
|||||
Name |
Text |
A name for the light sensor that is meaningful to the user. |
25 characters |
Tamper |
tamper.name |
Tamper Alert |
Alert |
Alert type for this event. See Warnings and Alarms. |
tamper.alert |
||
Magnetic Switch |
|||||
Mode |
Option |
Specifies the function of the Magnetic Switch. |
Disabled, Setup, Wake, Trigger, All |
Disabled |
magnet.mode |
Internal Temperature |
|||||
Name |
Text |
A name for the input that is meaningful to the user. |
25 characters |
Internal Temperature |
ambient.name |
Interval |
Integer |
The number of base intervals after which the temperature is sampled. A value of 1 means that the input is collected every base interval. Set to 0 to disable. |
0 to 10000 |
1 |
ambient.interval |
Temperature Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
Thresholds -40 to 100 °C |
ambient.alert |
|
Accelerometer |
|||||
Name |
Text |
A name for the input that is meaningful to the user. |
25 characters |
Accelerometer |
accel.name |
Interval |
Integer |
The number of base intervals after which the accelerometer is sampled. A value of 1 means that the input is collected every base interval. Set to 0 to disable. |
0 to 10000 |
0 |
accel.interval |
Output XYZ Vectors |
On/Off |
Send X,Y,Z gravity vectors in data output. |
Off |
accel.outputxyz |
|
Pitch Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
Thresholds -90 to 90 Degrees |
accel.pitch.alert |
|
Roll Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
Thresholds -90 to 90 Degrees |
accel.roll.alert |
|
Angle Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
Thresholds 0 to 90 Degrees |
accel.angle.alert |
|
Vibration Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
Thresholds 0 to 5000 milli-g |
accel.motion.alert |
|
Count Vibration Hours |
On/Off |
Counts the number of hours the device exceeds the Vibration Wake Threshold. Typically used as an machinery work vs idle hour meter. |
Off |
accel.motion.count_hours |
|
Wake from Sleep/Hibernate |
On/Off |
The high warning vibration threshold is used to wake the device when in sleep or hibernate. |
Off |
accel.motion.wake_from_hibernate |
|
Vibration Wake Threshold |
Decimal |
The vibration threshold above which the device will wake from hibernation. |
1 to 2000 milli-g |
100 |
accel.motion.wake_threshold |
Impact Alert 1 |
Alert |
Alert type, impact threshold and duration. See Accelerometer. |
accel.impact.alert1 |
||
Impact Alert 2 |
Alert |
Alert type, impact threshold and duration. See Accelerometer. |
accel.impact.alert2 |
||
Bluetooth |
|||||
Name |
Text |
A name that is meaningful to the user. |
25 characters |
Bluetooth |
ble.name |
Enable Bluetooth |
On/Off |
Enable the Bluetooth module. This must be enabled to use Bluetooth from a script, but reduces available RAM |
Off |
ble.enable |
|
Interval |
Integer |
The number of base intervals at which the Bluetooth module is turned on. Set to 0 to disable. |
0 to 10000 |
0 |
ble.interval |
Scan Time |
Integer |
How long to scan for Bluetooth advertisements each interval. |
1 to 300 Seconds |
5 |
ble.scan_time |
Address Capture List |
Text |
List of addresses to be captured in HEX format, separated by a comma eg: AC233F6925AD. Leave blank to capture all. |
200 characters |
ble.id_list |
|
Send Raw Data |
On/Off |
Send all captured data in the standard data message. If unticked, data is only delivered to the scripting handler. |
Off |
ble.send_data |
|
GPS |
|||||
Name |
Text |
A name for the GPS signal that is meaningful to the user. |
25 characters |
GPS |
gps.name |
Interval |
Integer |
The number of base intervals after which the gps is sampled. A value of 1 means that the input is collected every base interval. Set to 0 to disable. |
0 to 10000 |
0 |
gps.interval |
Max Time |
Integer |
Maximum time the device will wait for a valid GPS fix. |
0 to 3600 Seconds |
180 |
gps.maxtime |
Position |
|||||
Expected Latitude |
Decimal |
Latitude at which the device is expected to be. |
-90.0 to 90.0 Degrees |
-32.93197 |
gps.position.lat |
Expected Longitude |
Decimal |
Longitude at which the device is expected to be. |
-180.0 to 180.0 Degrees |
151.77883 |
gps.position.lon |
Expected Position Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
gps.position.alert |
||
Speed |
|||||
Speed Alert |
Alert |
Alert type, low and high thresholds and hysteresis. See Warnings and Alarms. |
gps.speed.alert |
||
Count Movement Hours |
On/Off |
Counts the number of hours the device is moving according to the GPS speed. |
Off |
gps.speed.count_hours |